
Unit DoF9
SKU:U229
Description
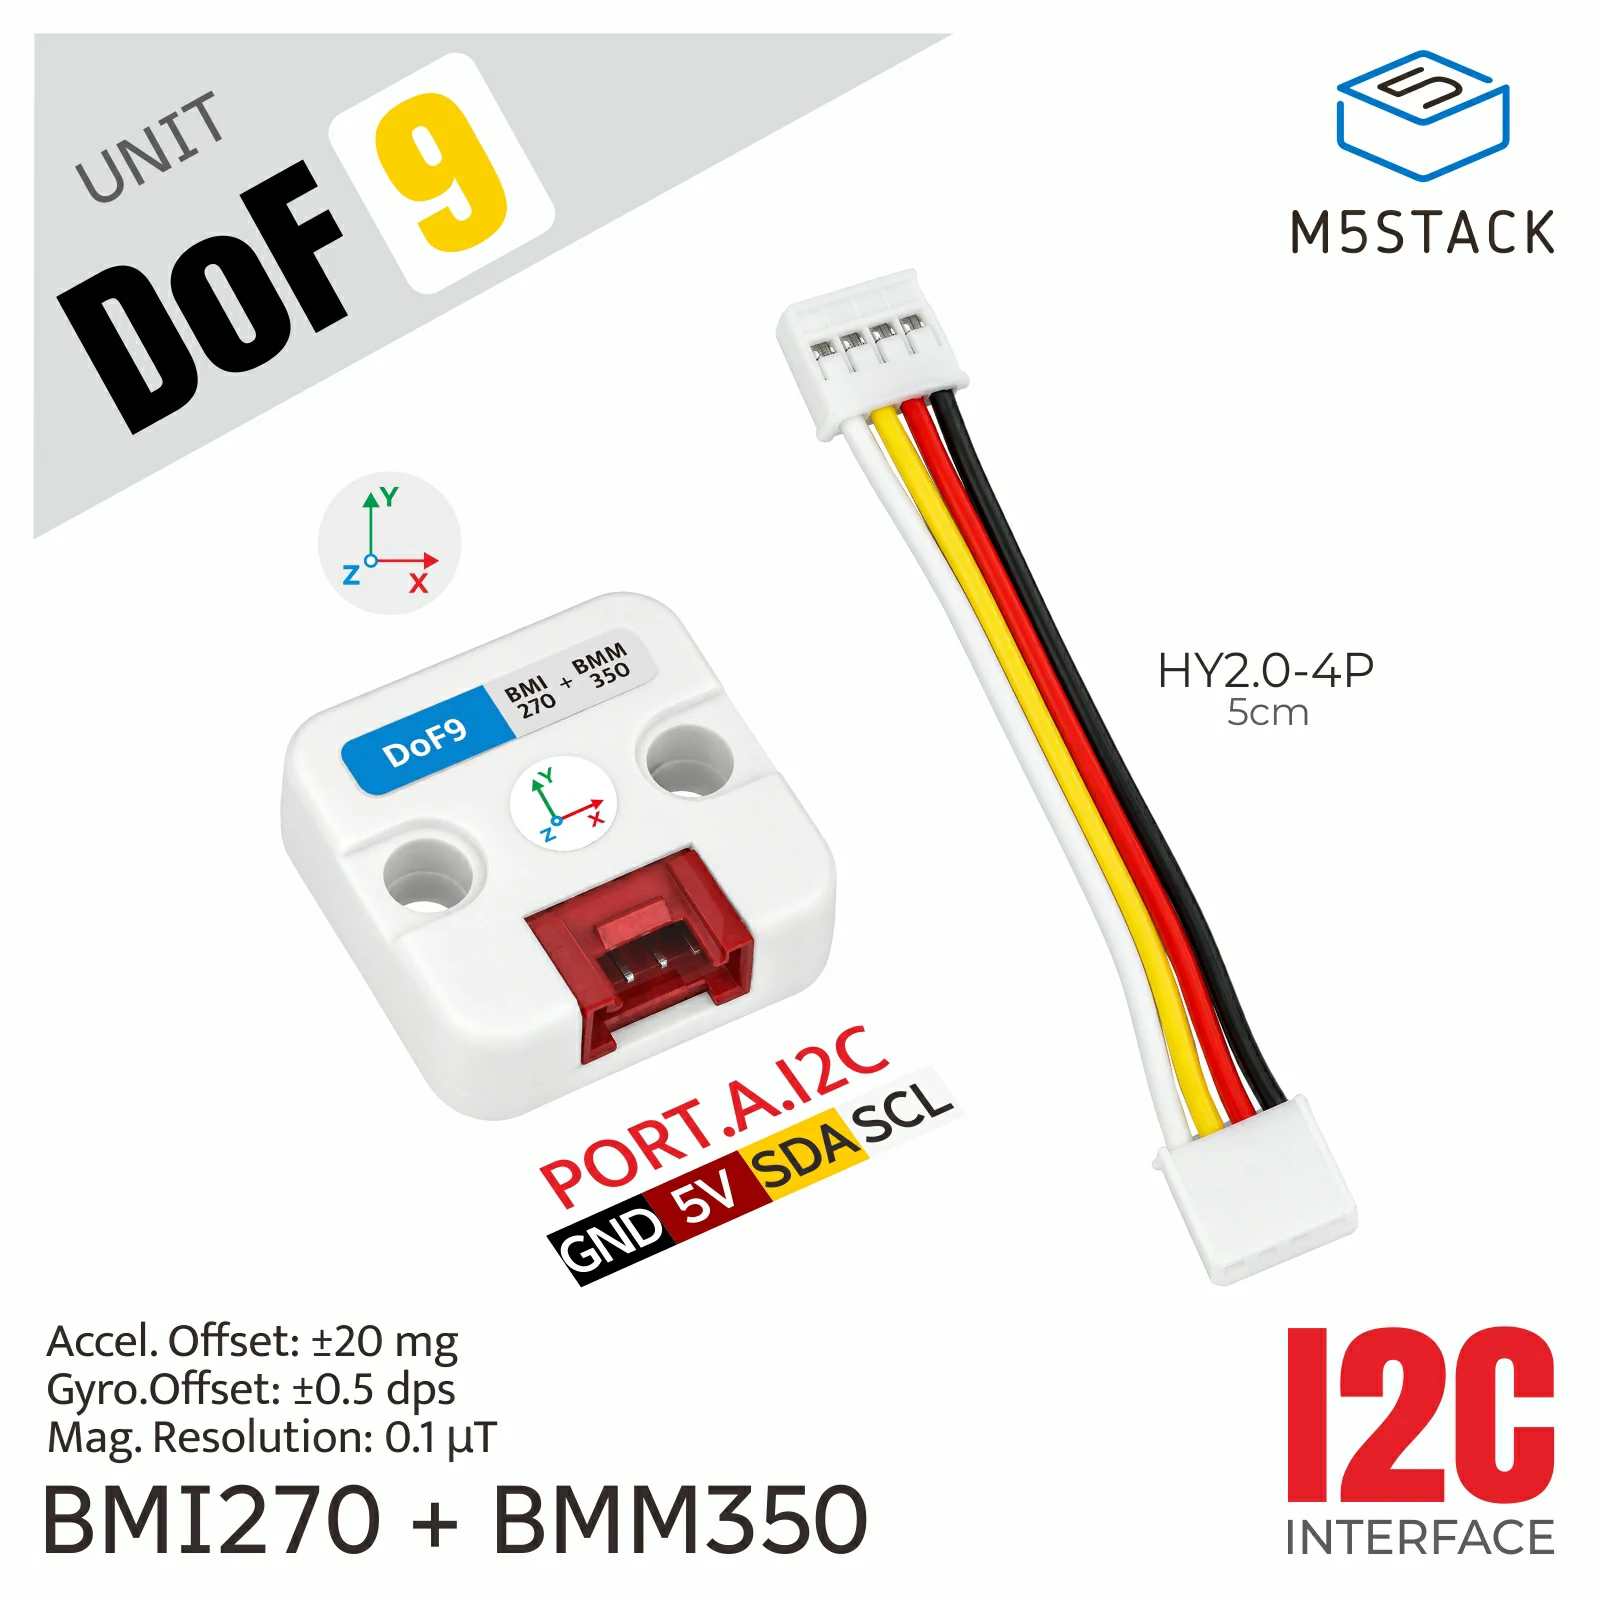
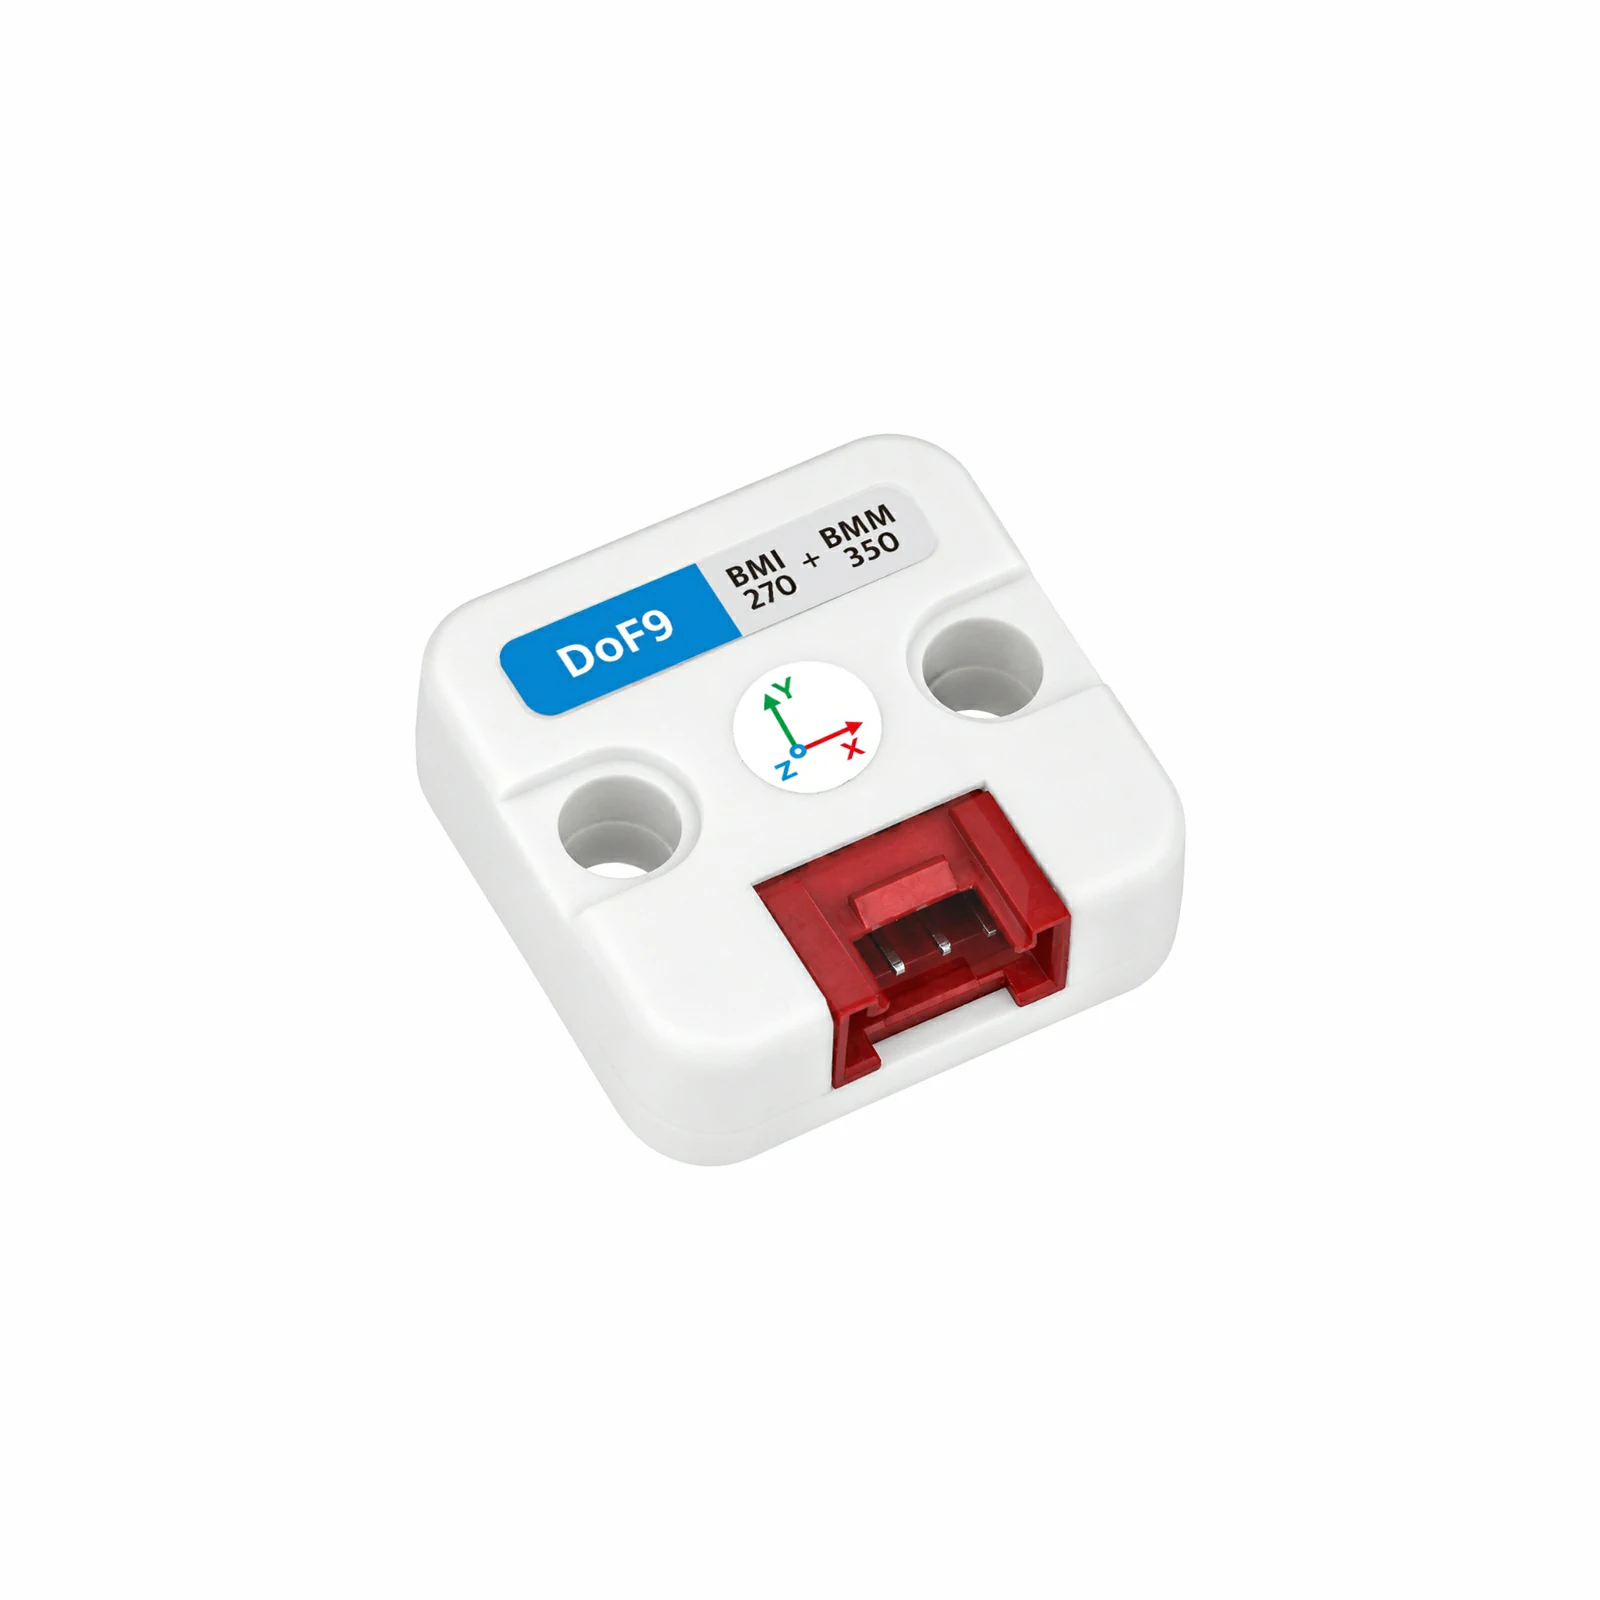
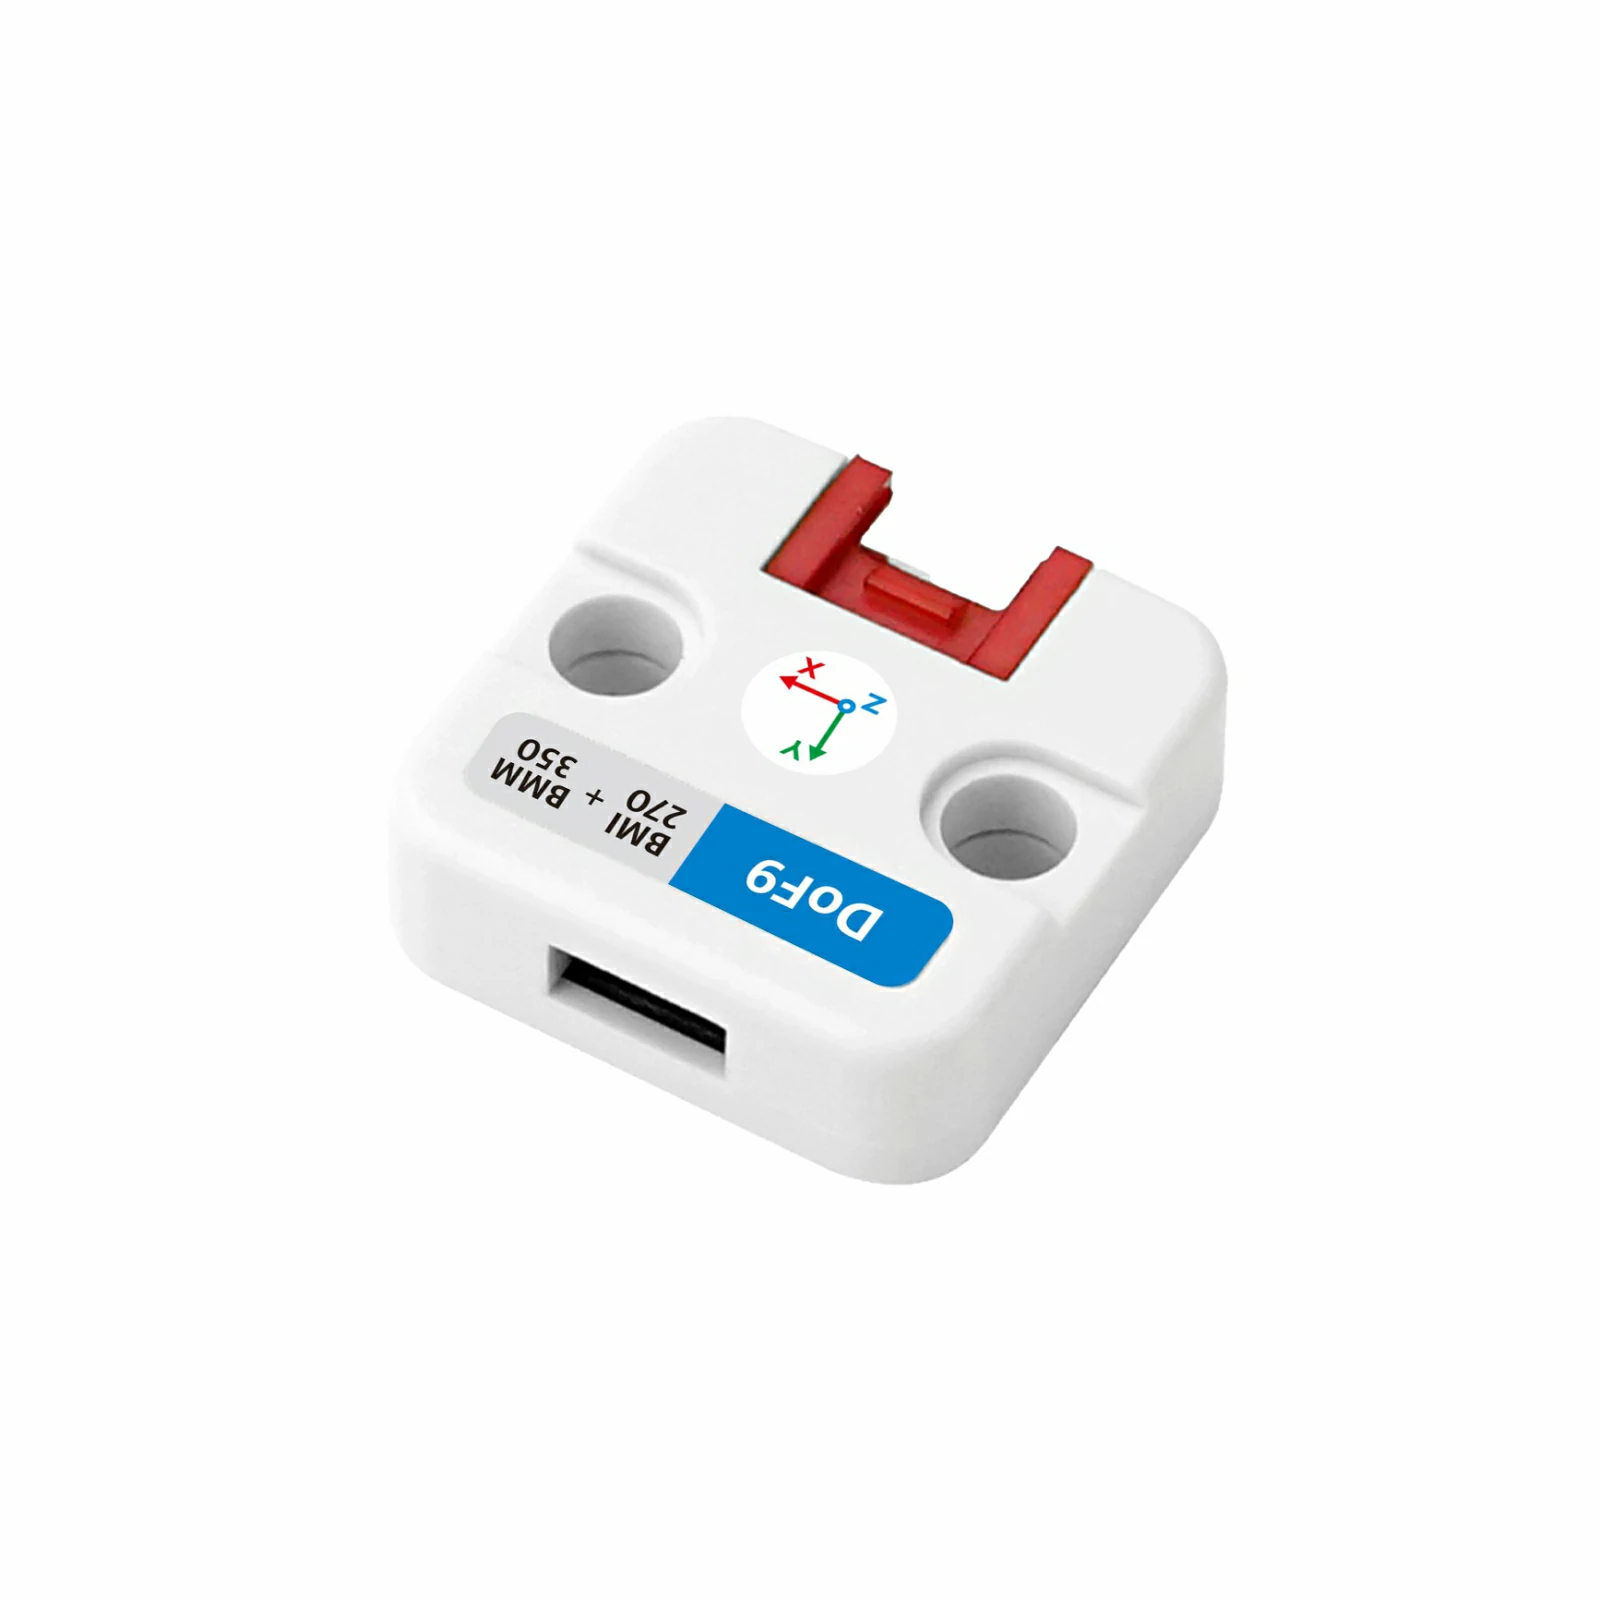
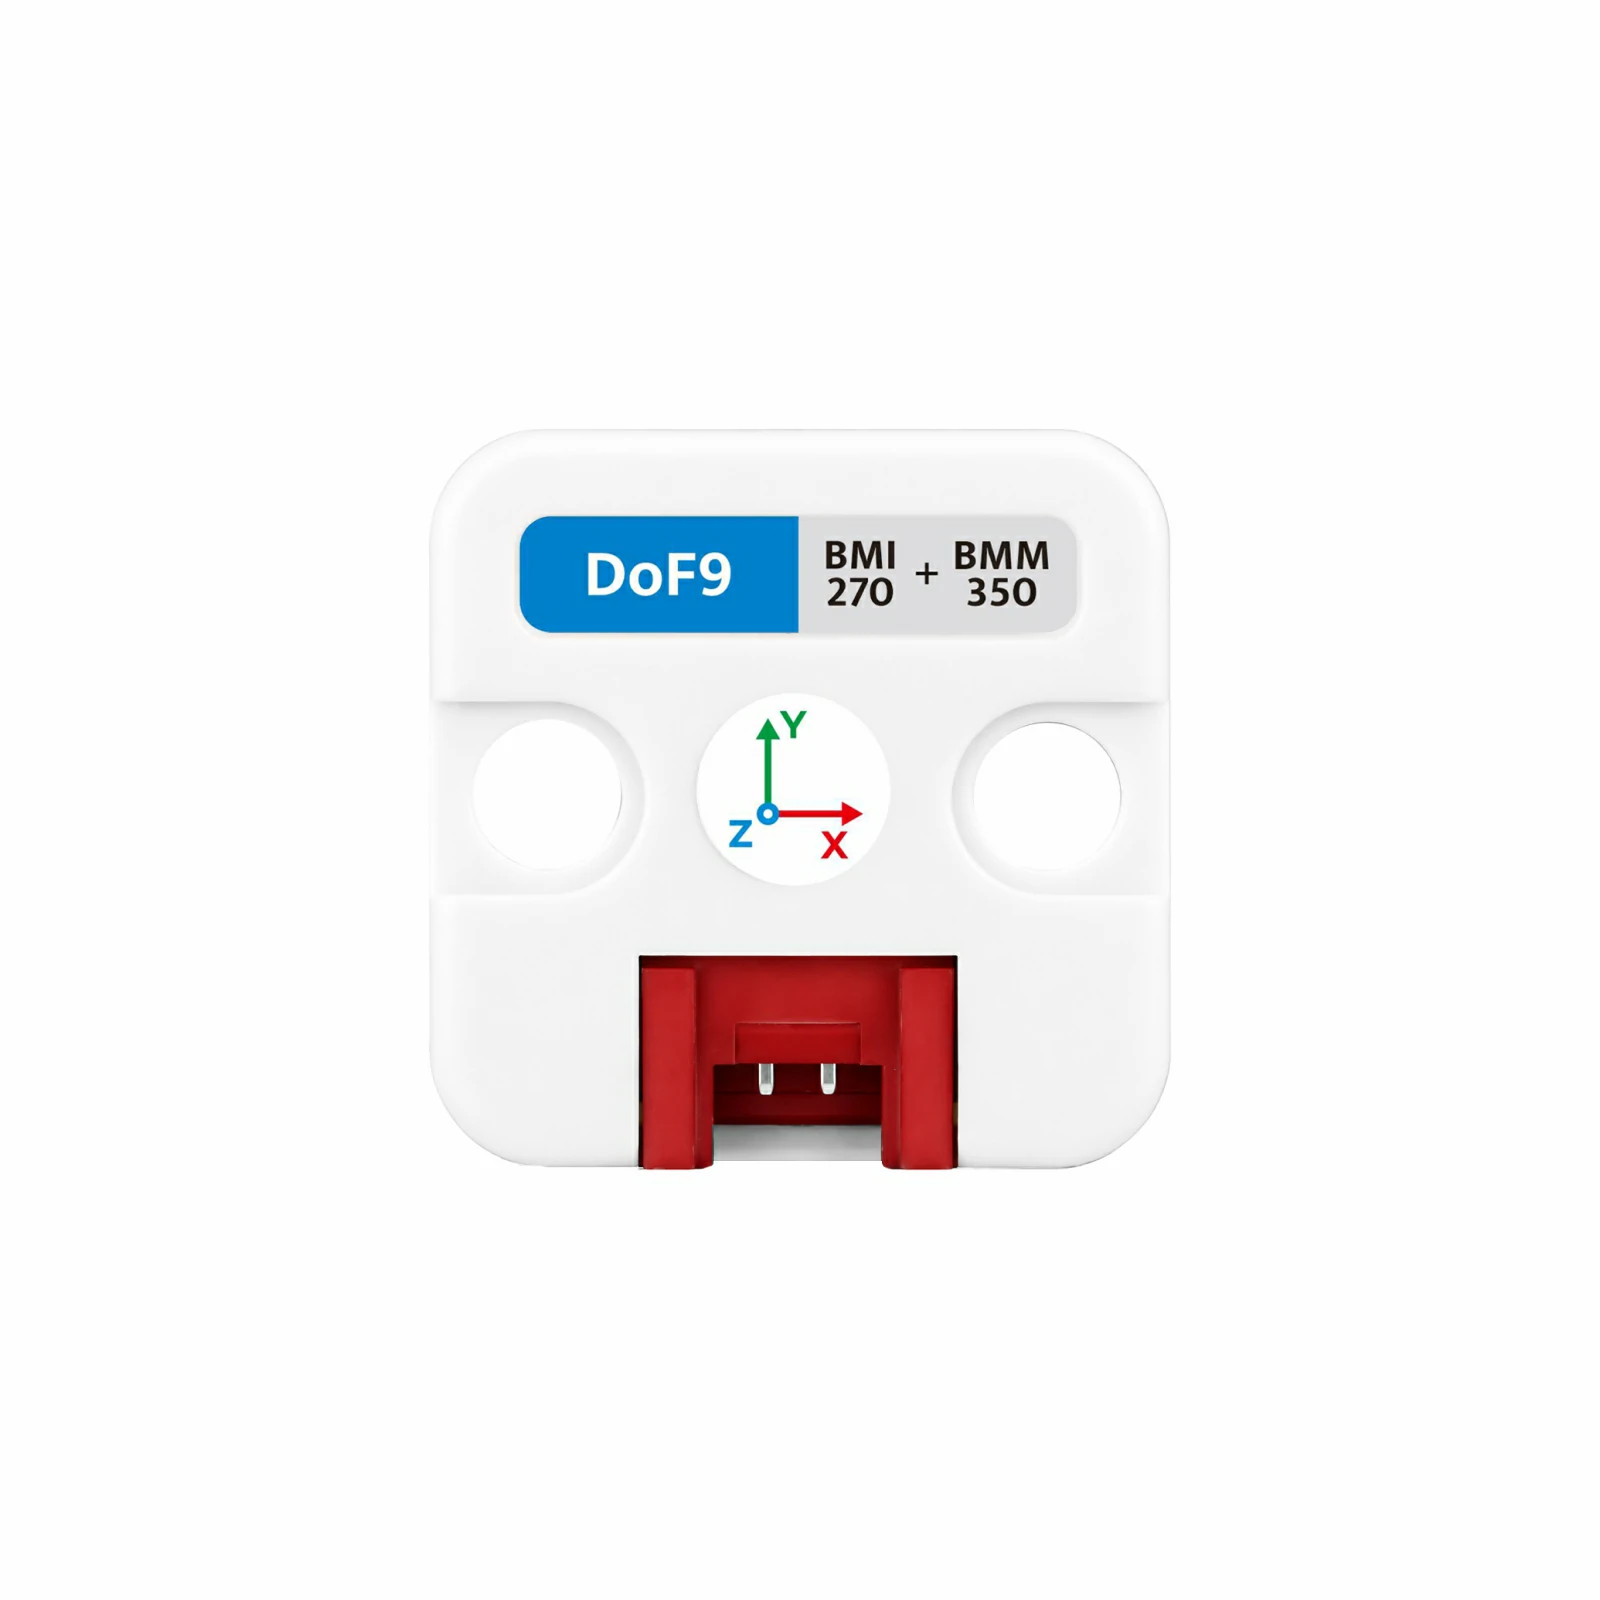
Unit DoF9 is a nine-axis attitude sensing unit that combines a six-axis inertial sensor with a three-axis magnetometer. It features the low-power BMI270 IMU and the BMM350 three-axis magnetometer. The BMI270 integrates a 16-bit 3-axis accelerometer and a 16-bit 3-axis gyroscope, with configurable measurement ranges and on-chip motion detection. The BMM350 uses TMR (tunnel magnetoresistance) technology for three-axis magnetic field measurement, achieving approximately 0.1 μT resolution and excellent temperature stability. Data is transmitted over I2C, providing real-time acceleration, angular velocity, temperature, and three-axis magnetic field data for robot attitude sensing, heading detection, electronic compass, motion tracking, navigation assistance, and gimbal control.
Features
- Integrated six-axis inertial and three-axis geomagnetic sensors
- 16-bit accelerometer and gyroscope sampling
- TMR magnetometer with high magnetic field resolution of 0.1 μT
- Real-time acquisition of inertial, temperature, and magnetic field data
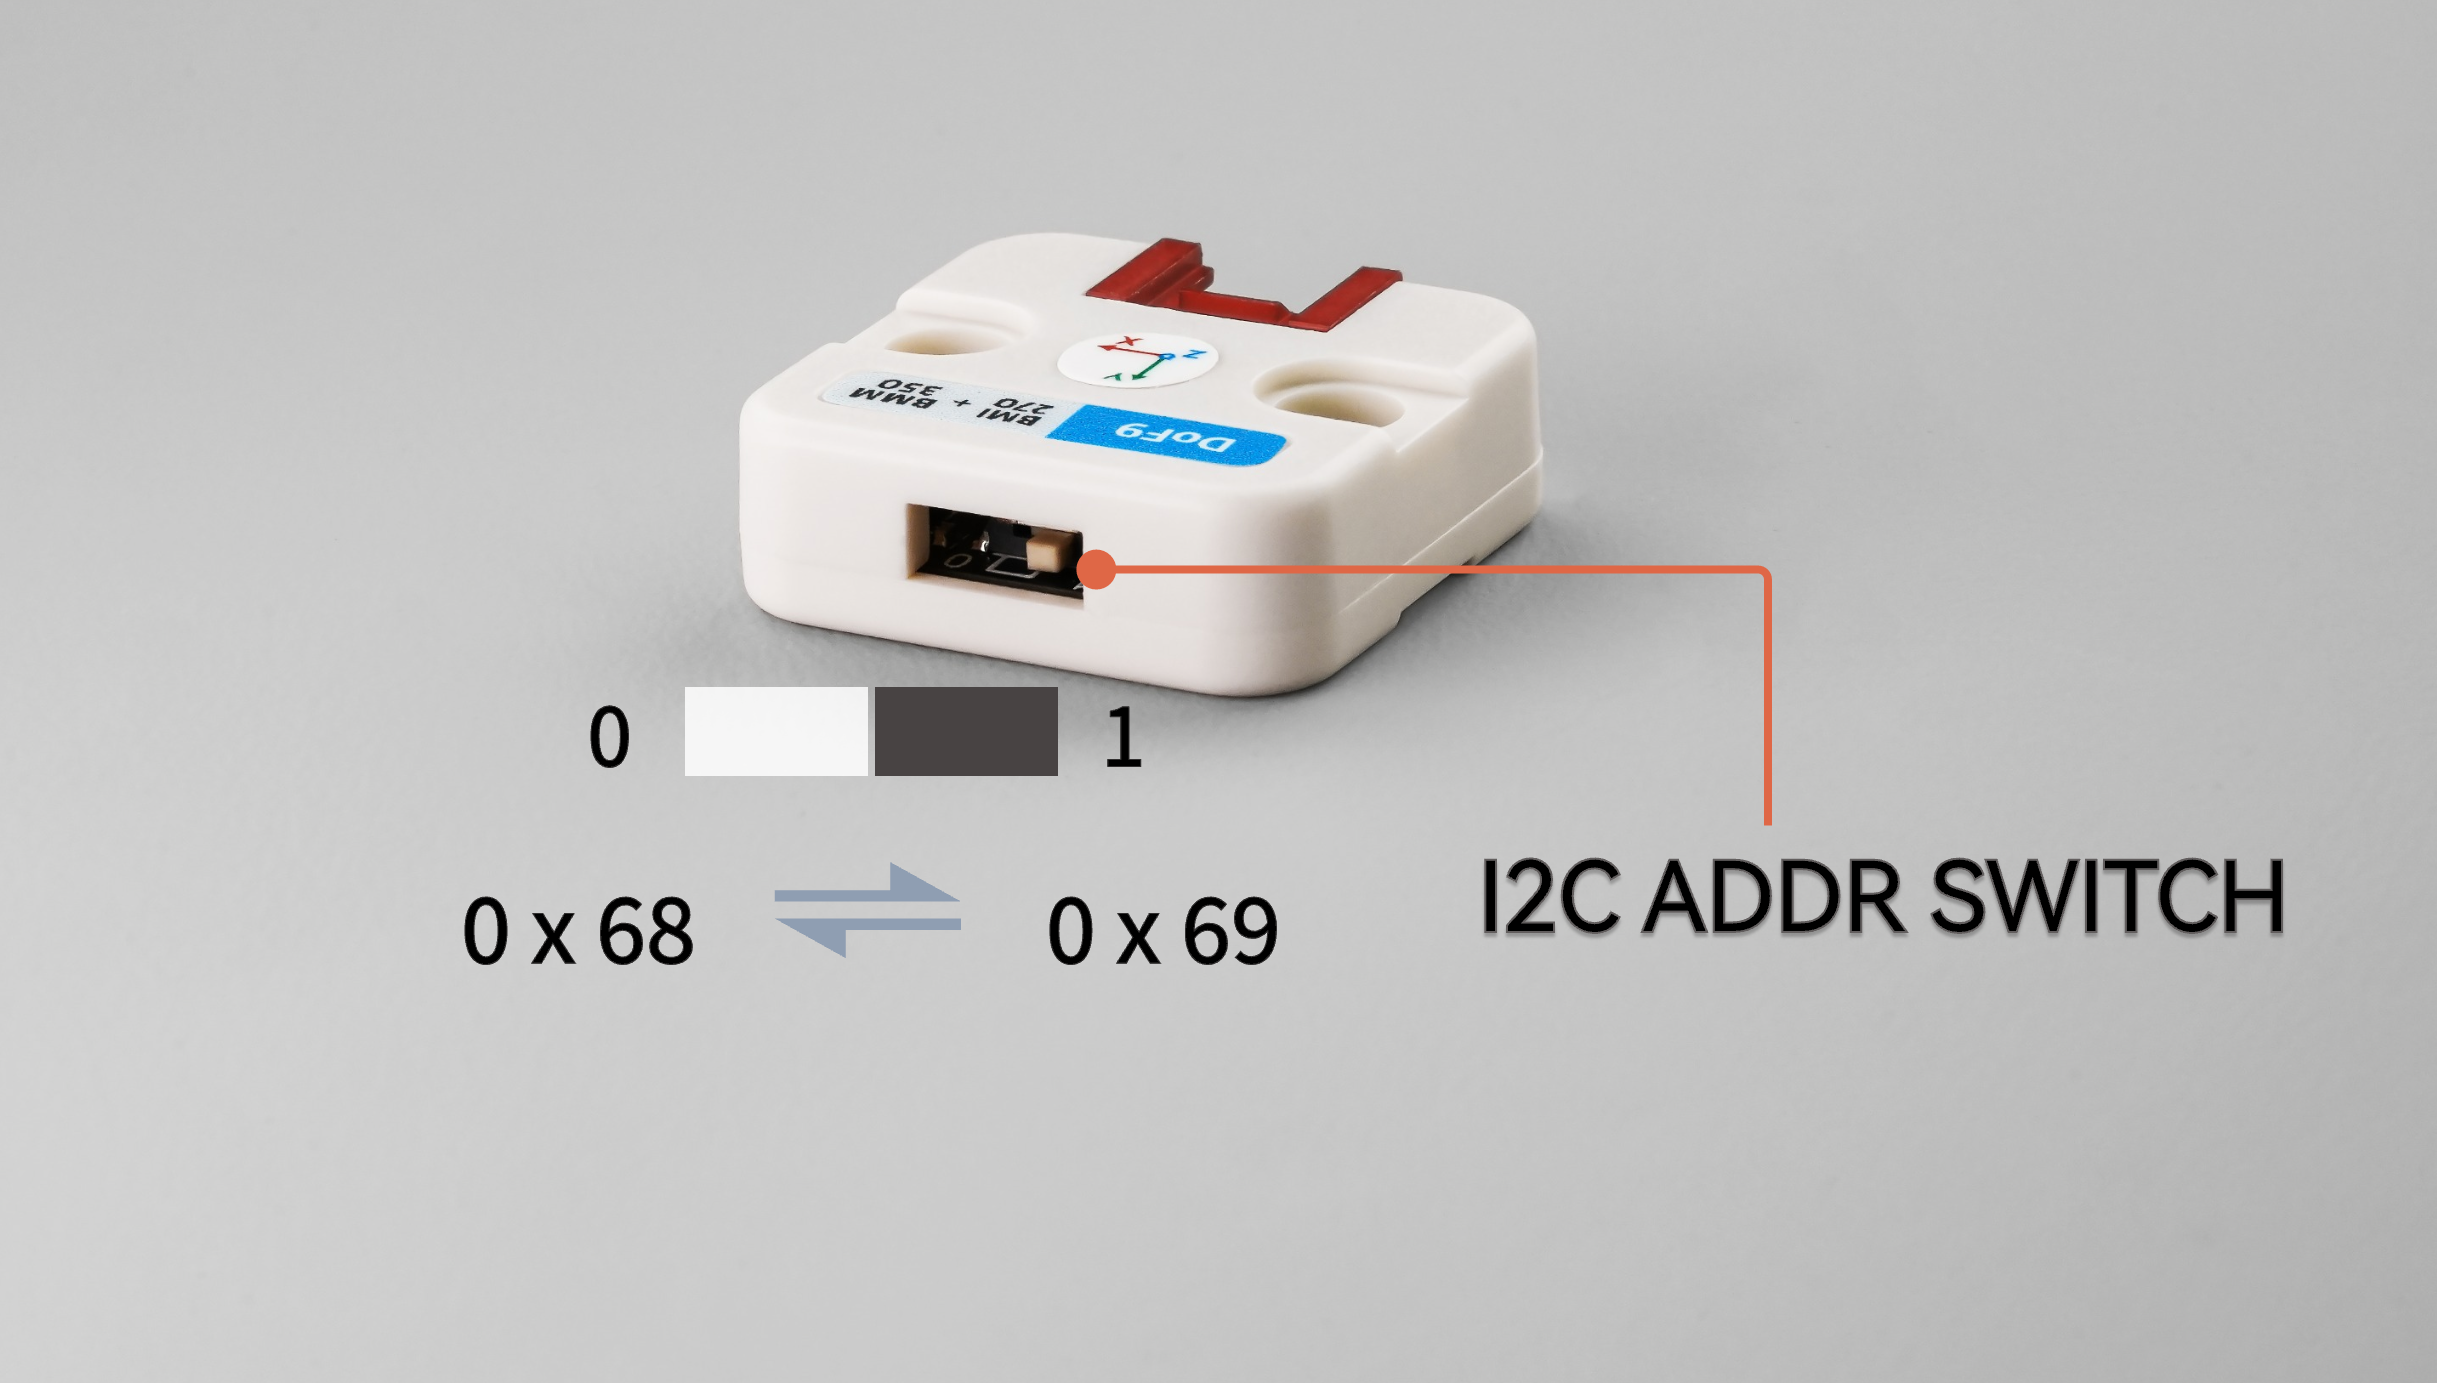
- I2C interface with BMI270 address switching
Includes
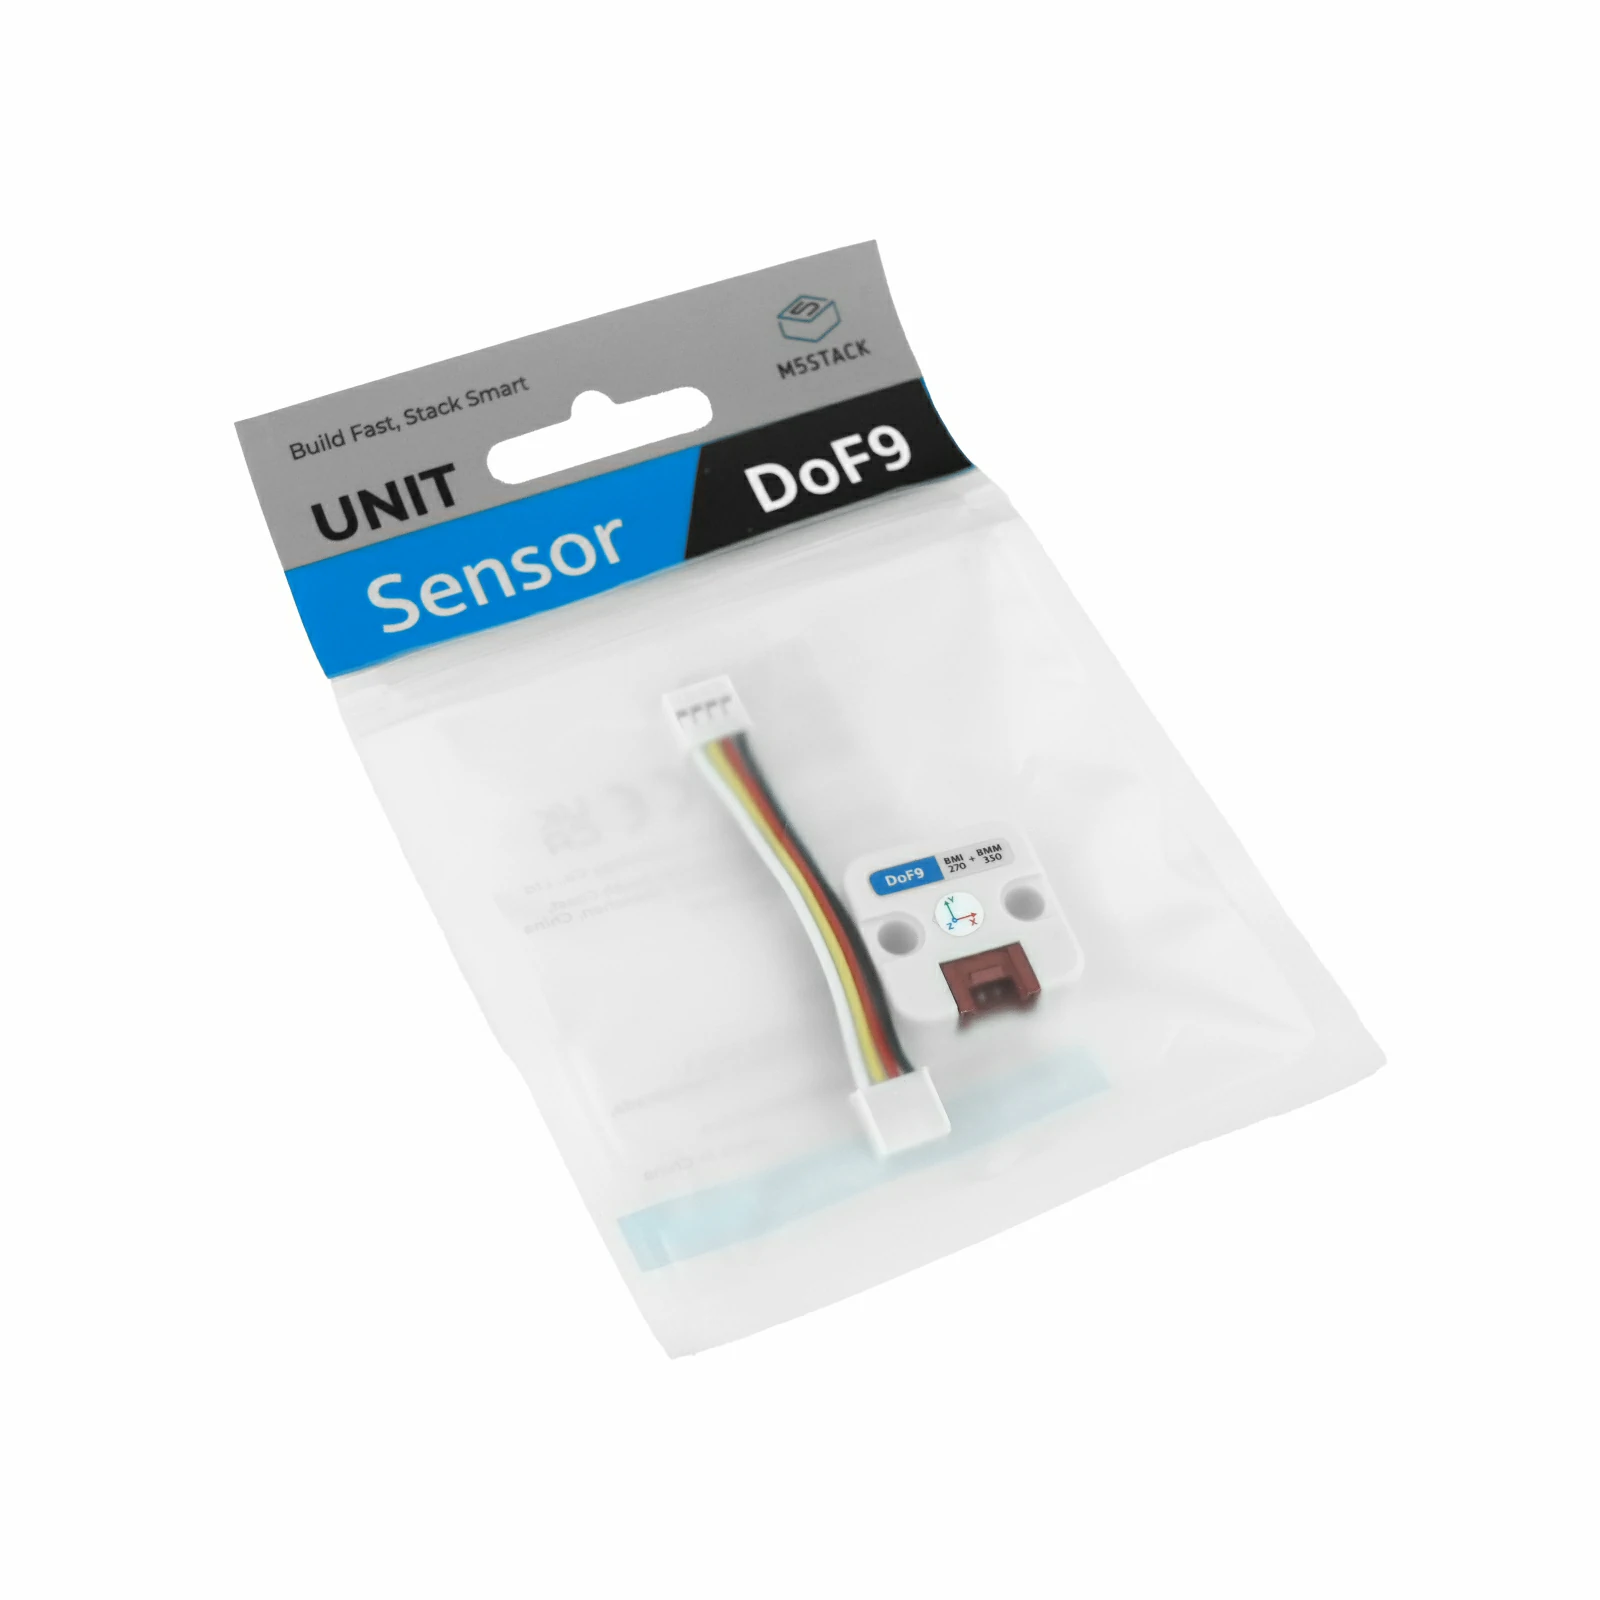
- 1 x Unit DoF9
- 1 x HY2.0-4P Grove Cable (5cm)
Applications
- Robot attitude sensing
- Heading detection
- Electronic compass
- Motion tracking
- Navigation assistance
- Gimbal control
Specifications
| Specification | Parameter |
|---|---|
| Inertial Sensor IC | BMI270 |
| Geomagnetic Sensor IC | BMM350 |
| Sensor Type | Six-axis inertial and three-axis geomagnetic sensor |
| Accelerometer | 16-bit 3-axis accelerometer |
| Accelerometer Range | ±2 g / ±4 g / ±8 g / ±16 g |
| Accelerometer Accuracy | ±20 mg (approx. ±0.02 g) |
| Gyroscope | 16-bit 3-axis gyroscope |
| Gyroscope Range | ±125 / ±250 / ±500 / ±1000 / ±2000 °/s |
| Gyroscope Accuracy | ±0.5 °/s |
| Magnetometer | BMM350 three-axis magnetometer |
| Magnetic Field Range | X/Y/Z axes: ±2000 μT (typical on each axis) |
| Magnetic Field Resolution | approx. 0.1 μT |
| BMI270 I2C Address | I2C @ 0x68 / 0x69 (switchable via onboard switch) |
| BMM350 I2C Address | I2C @ 0x14 |
| Product Size | 24.0 x 24.0 x 8.0mm |
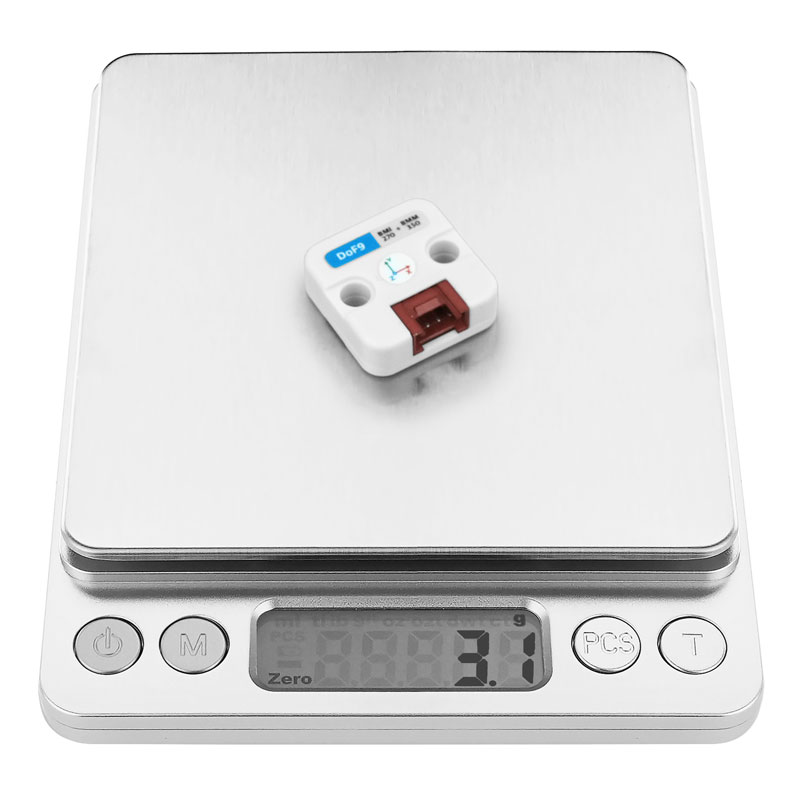
| Product Weight | 3.1g |
| Package Size | 138.0 x 93.0 x 7.0mm |
| Gross Weight | 6.6g |
Learn
I2C Address Switching
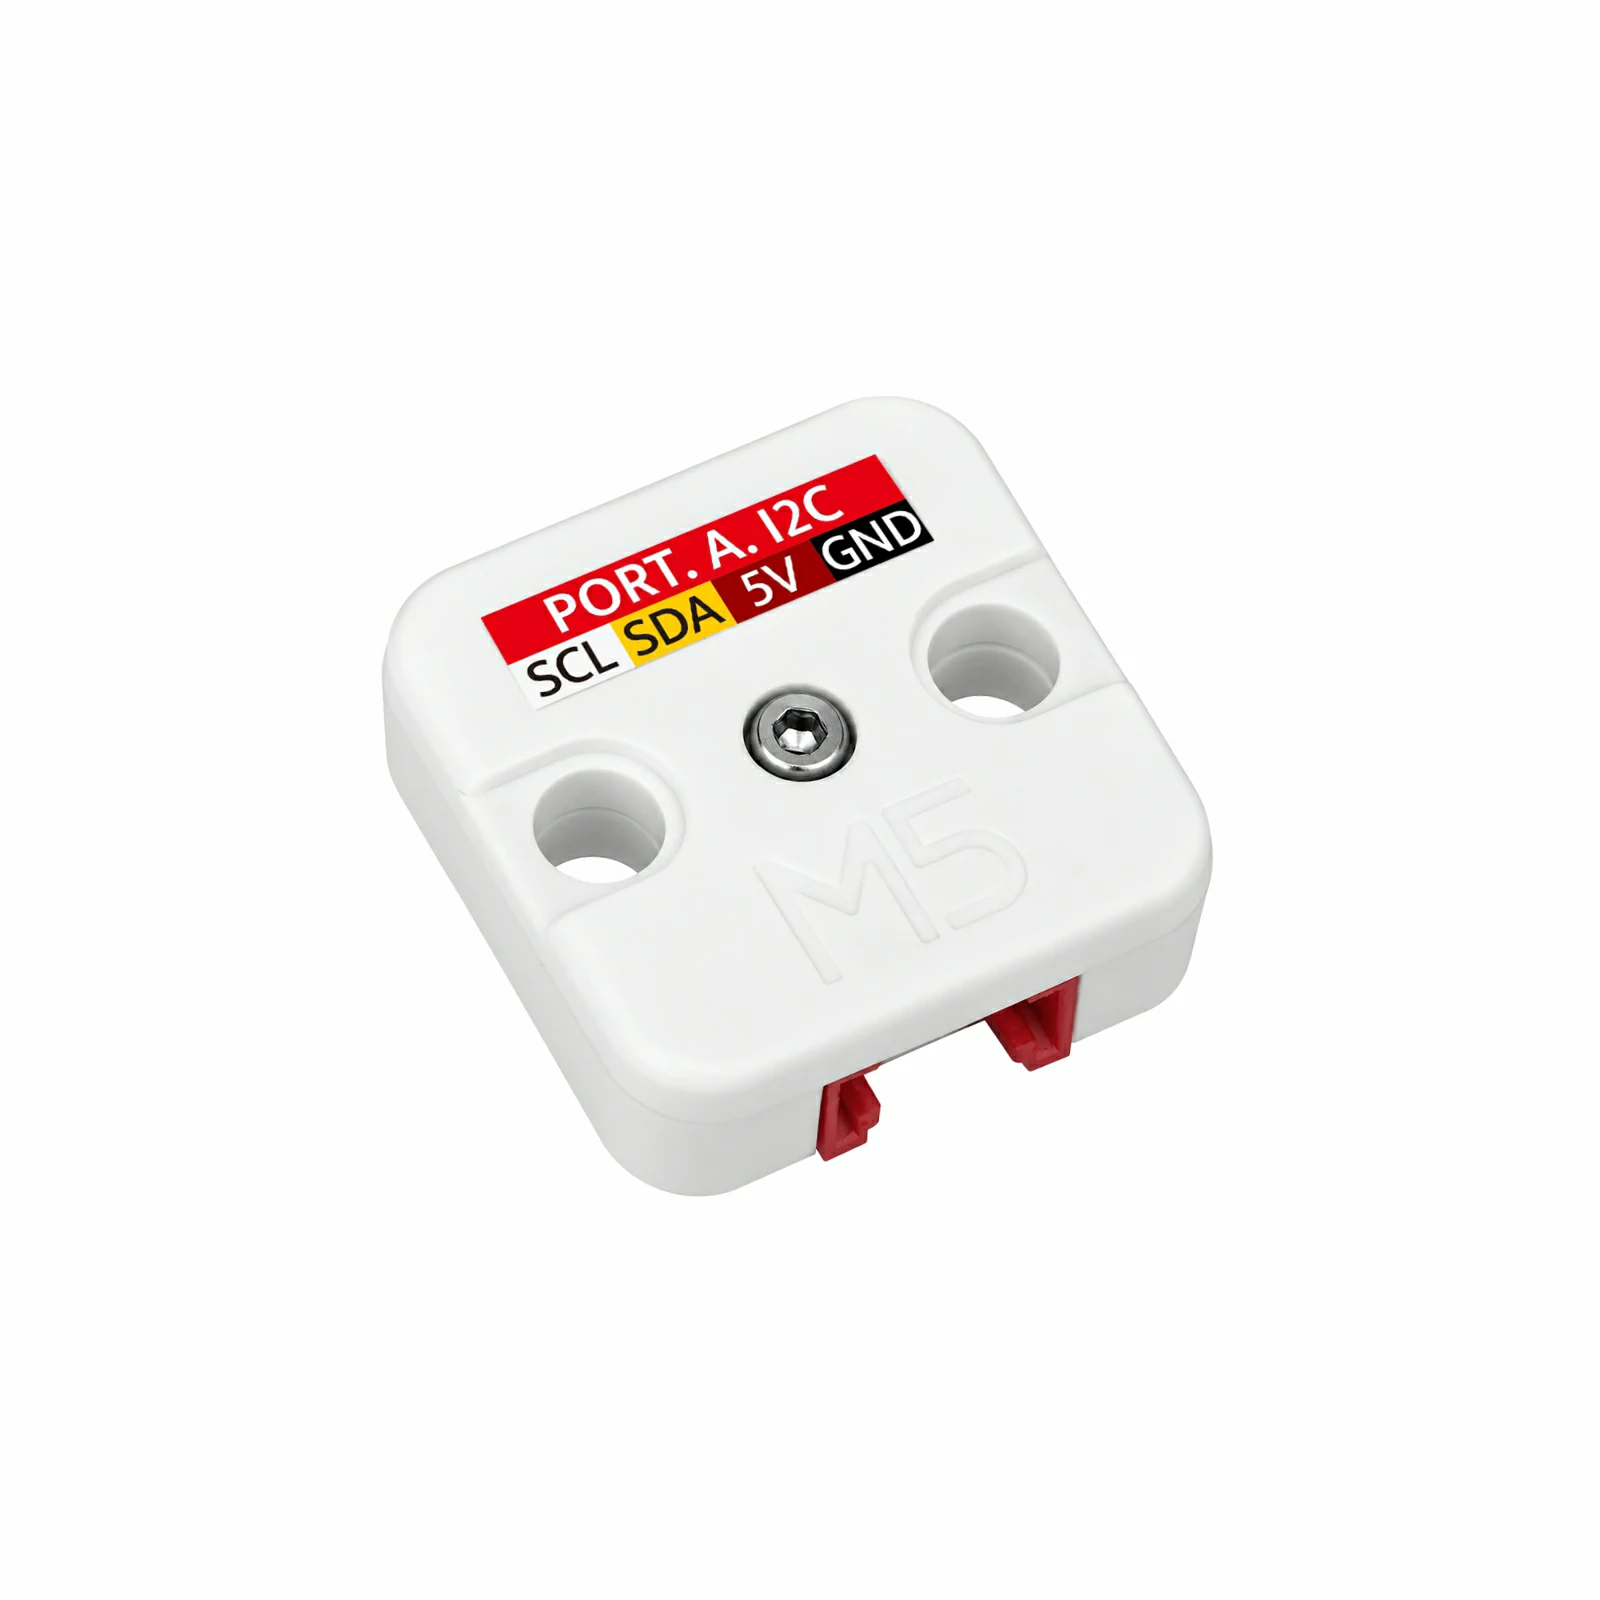
The BMI270 I2C address can be switched with the onboard switch. Set the switch to 0 for address 0x68, or to 1 for address 0x69, to avoid address conflicts on the I2C bus.
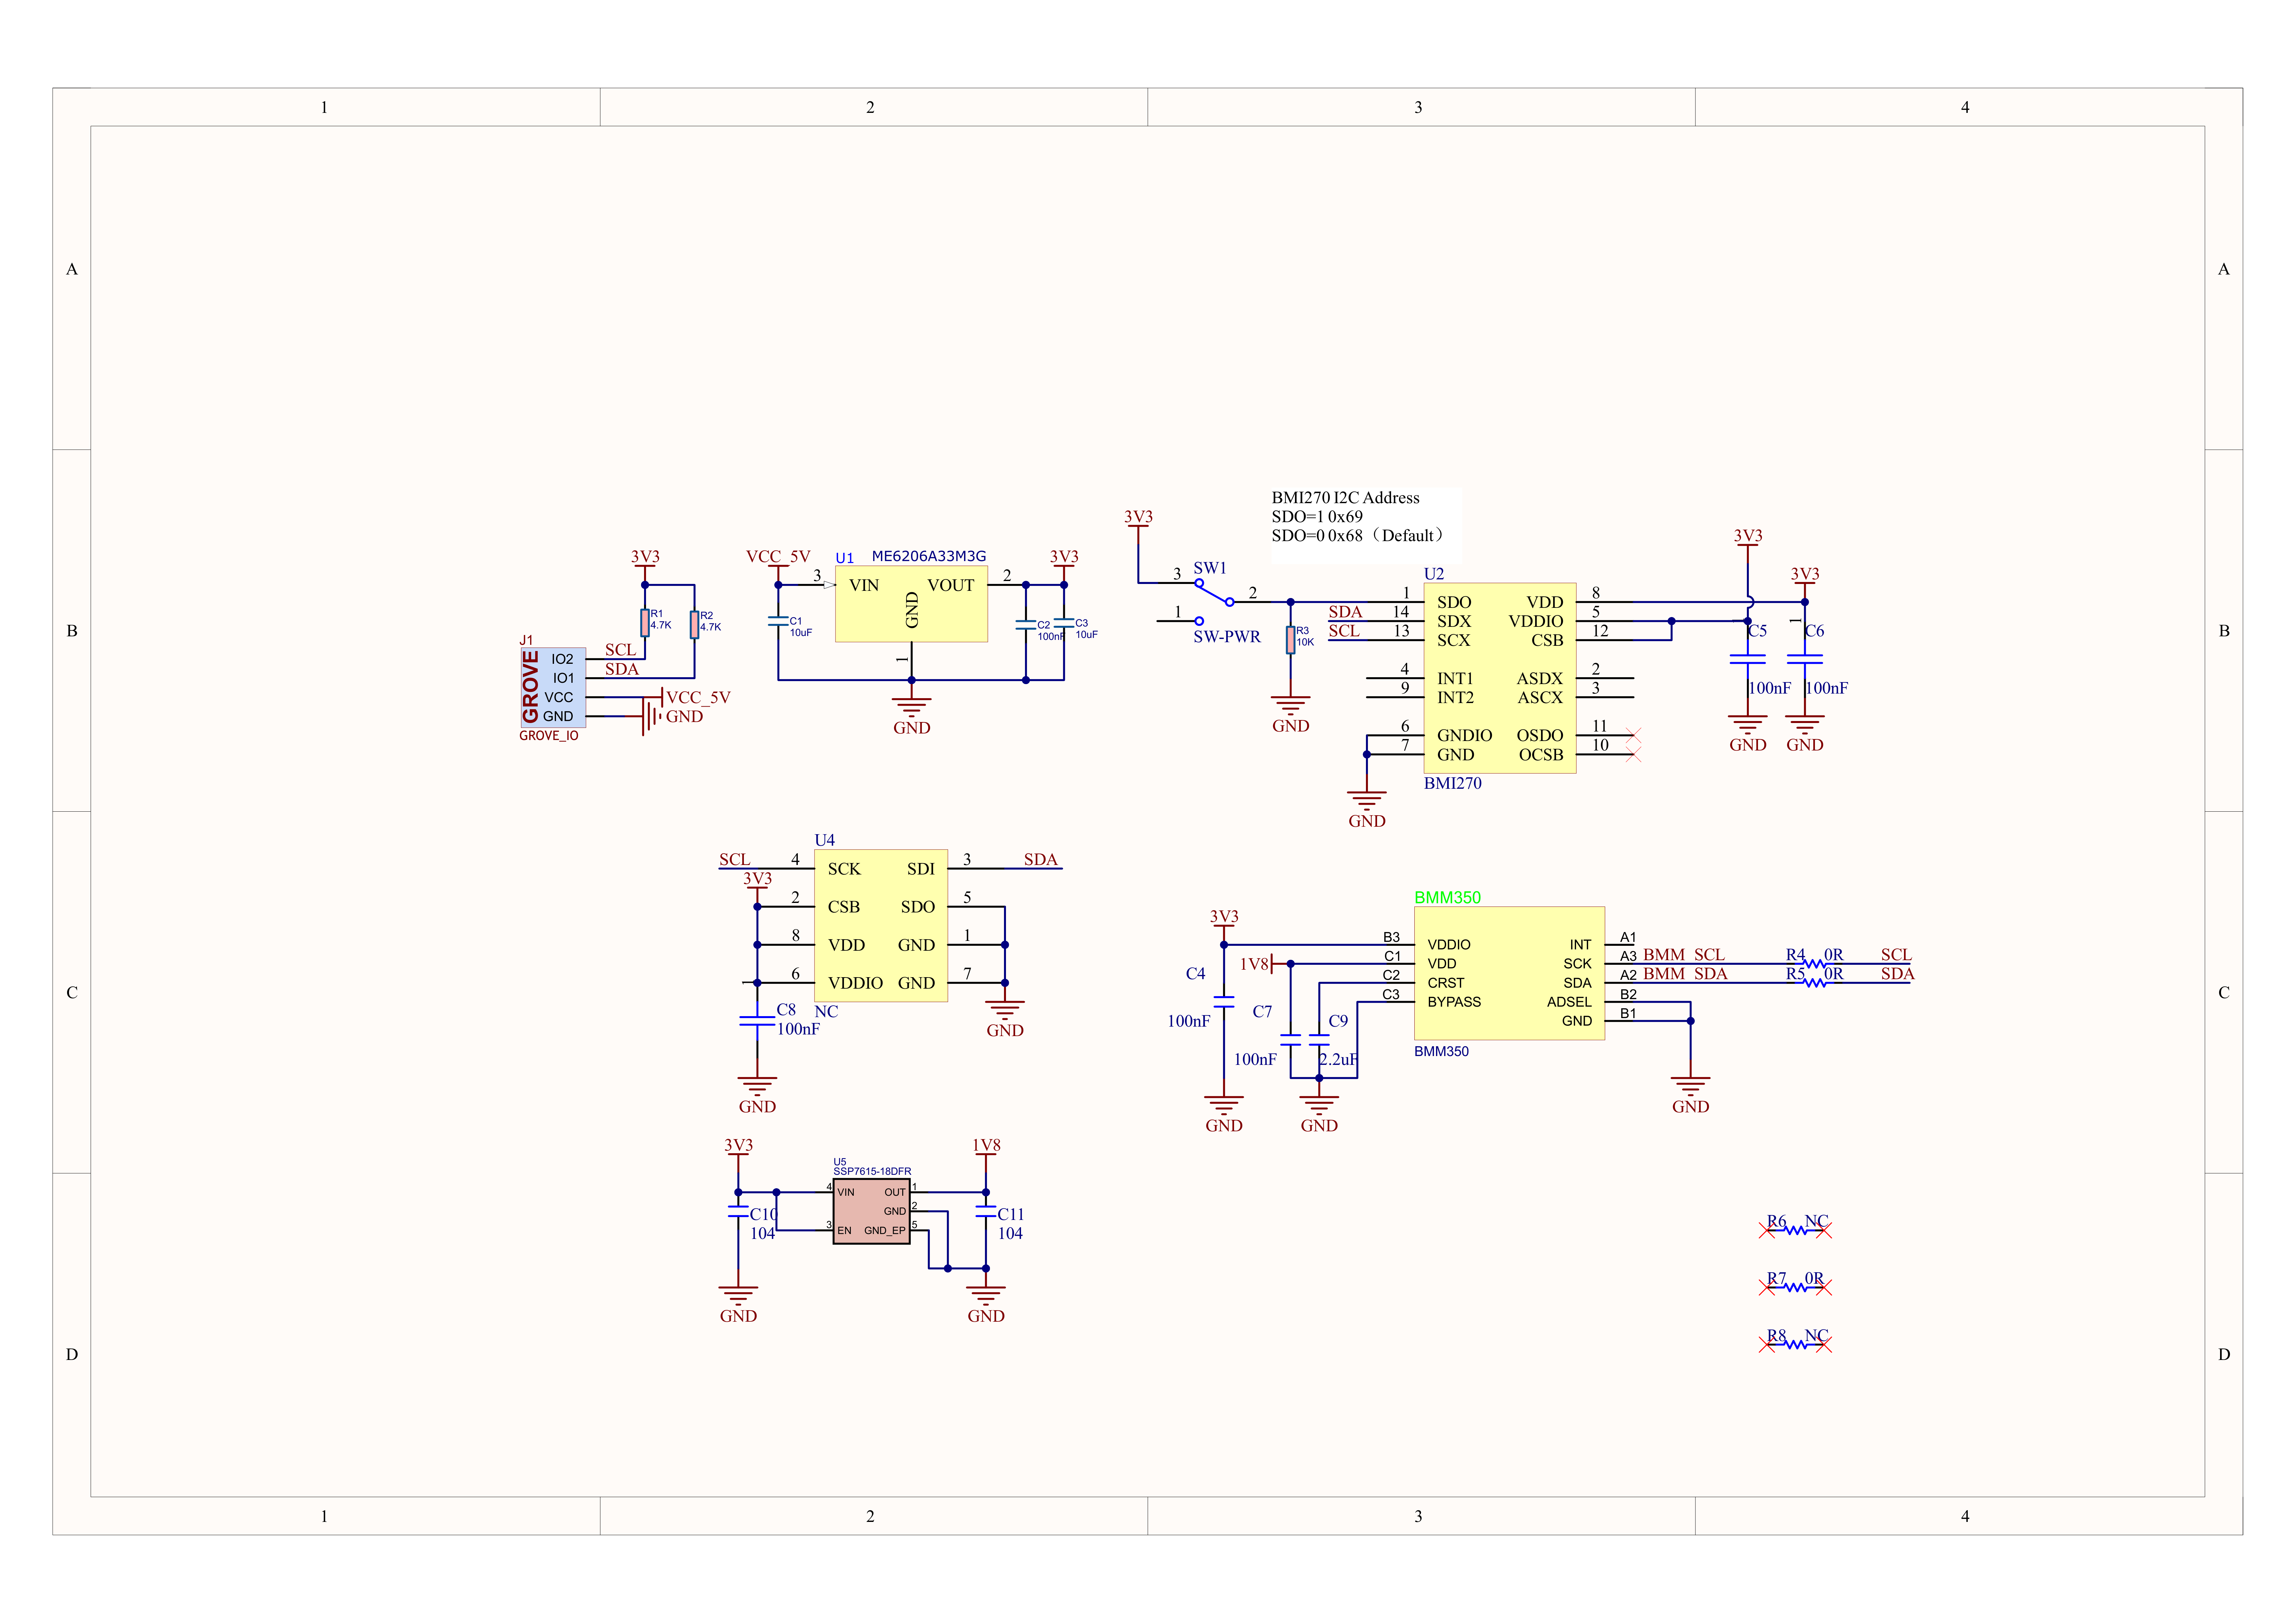
Schematics
PinMap
Unit DoF9
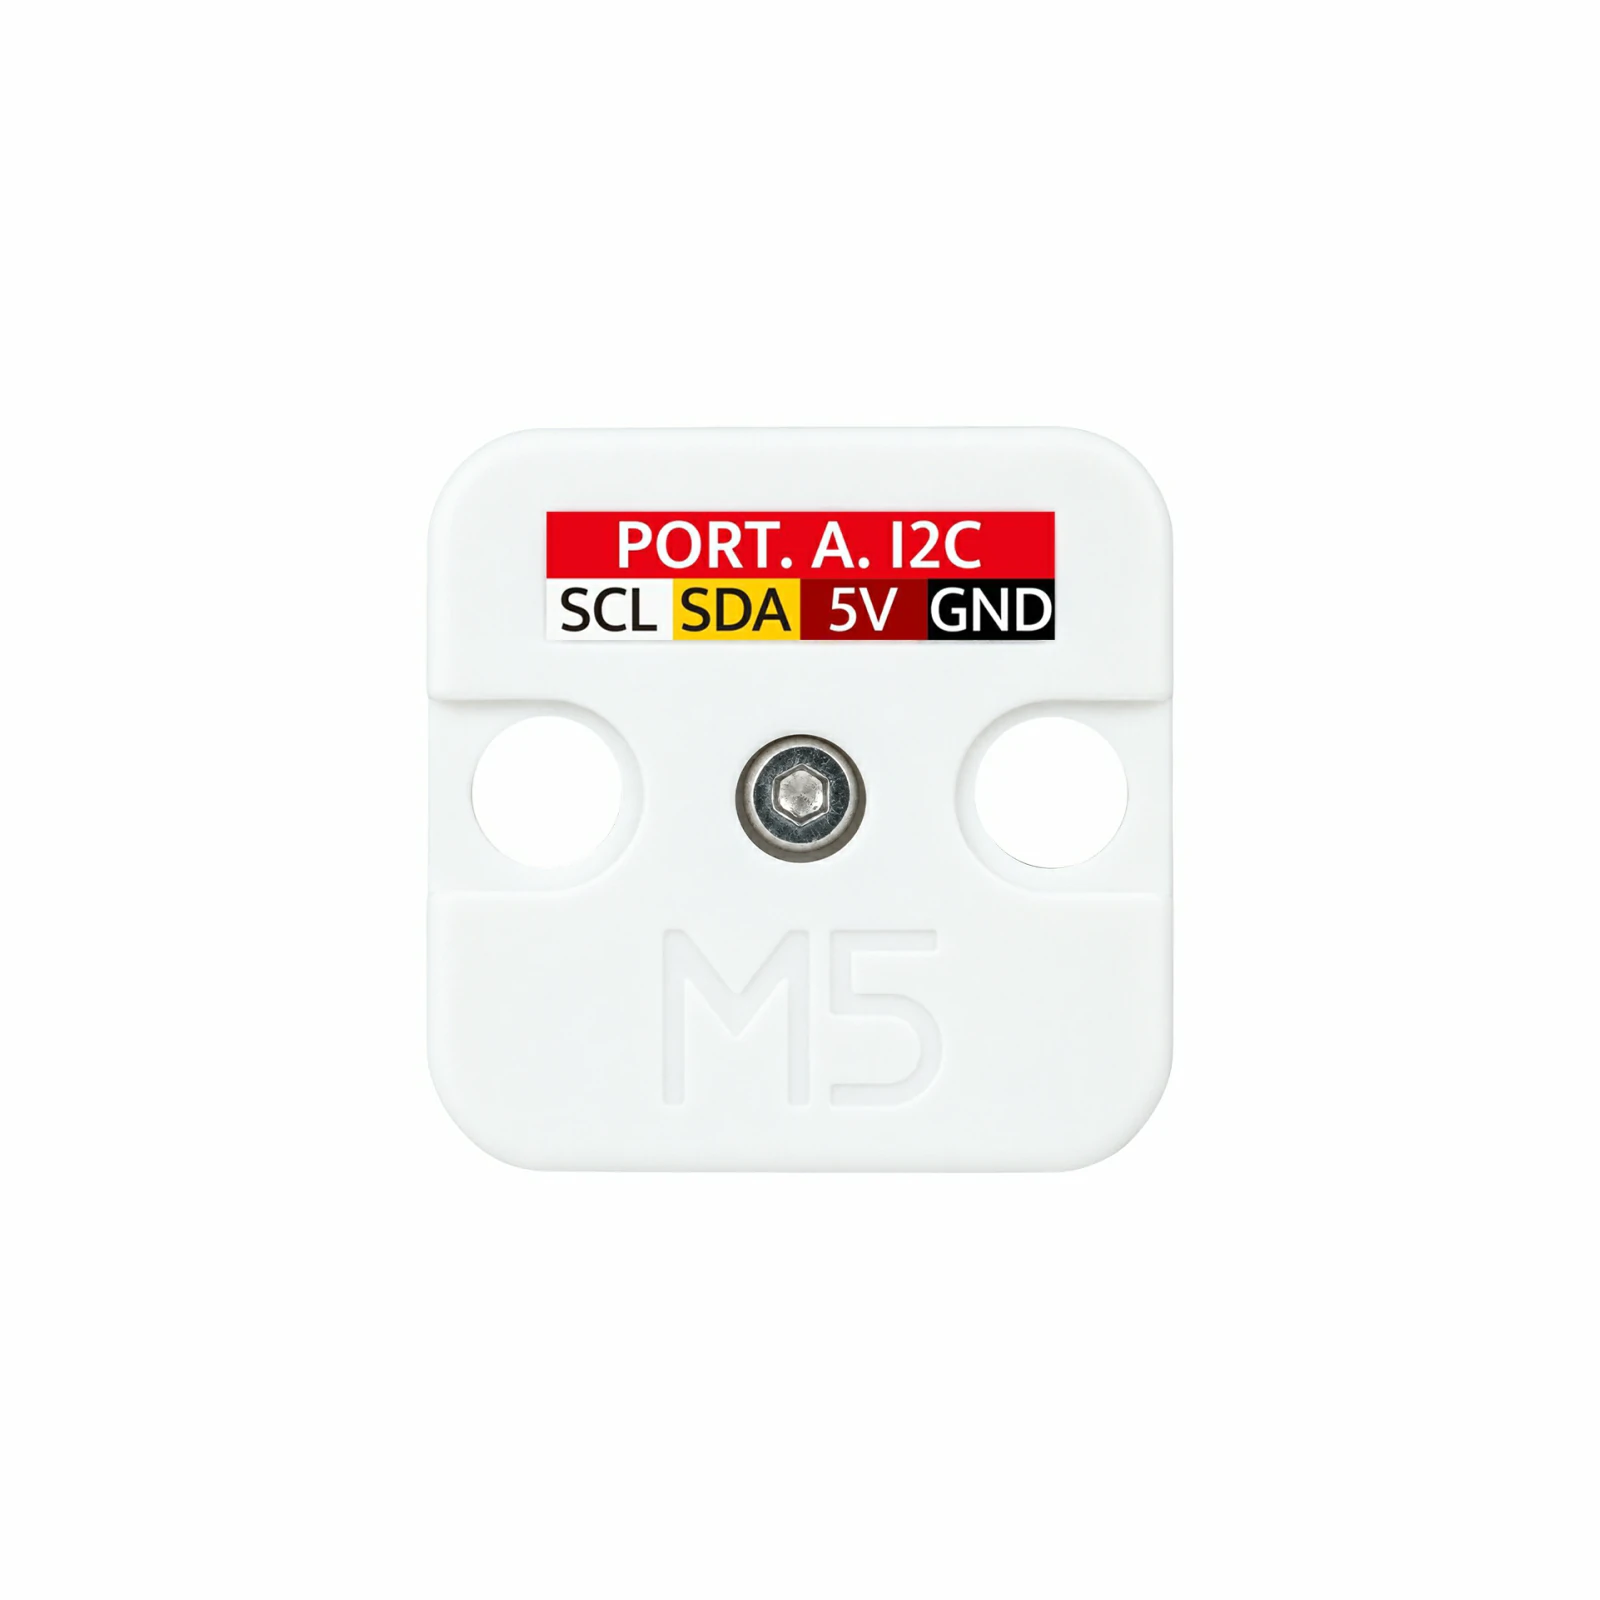
| HY2.0-4P | Black | Red | Yellow | White |
|---|---|---|---|---|
| PORT.A | GND | 5V | SDA | SCL |
Datasheets
Model Size
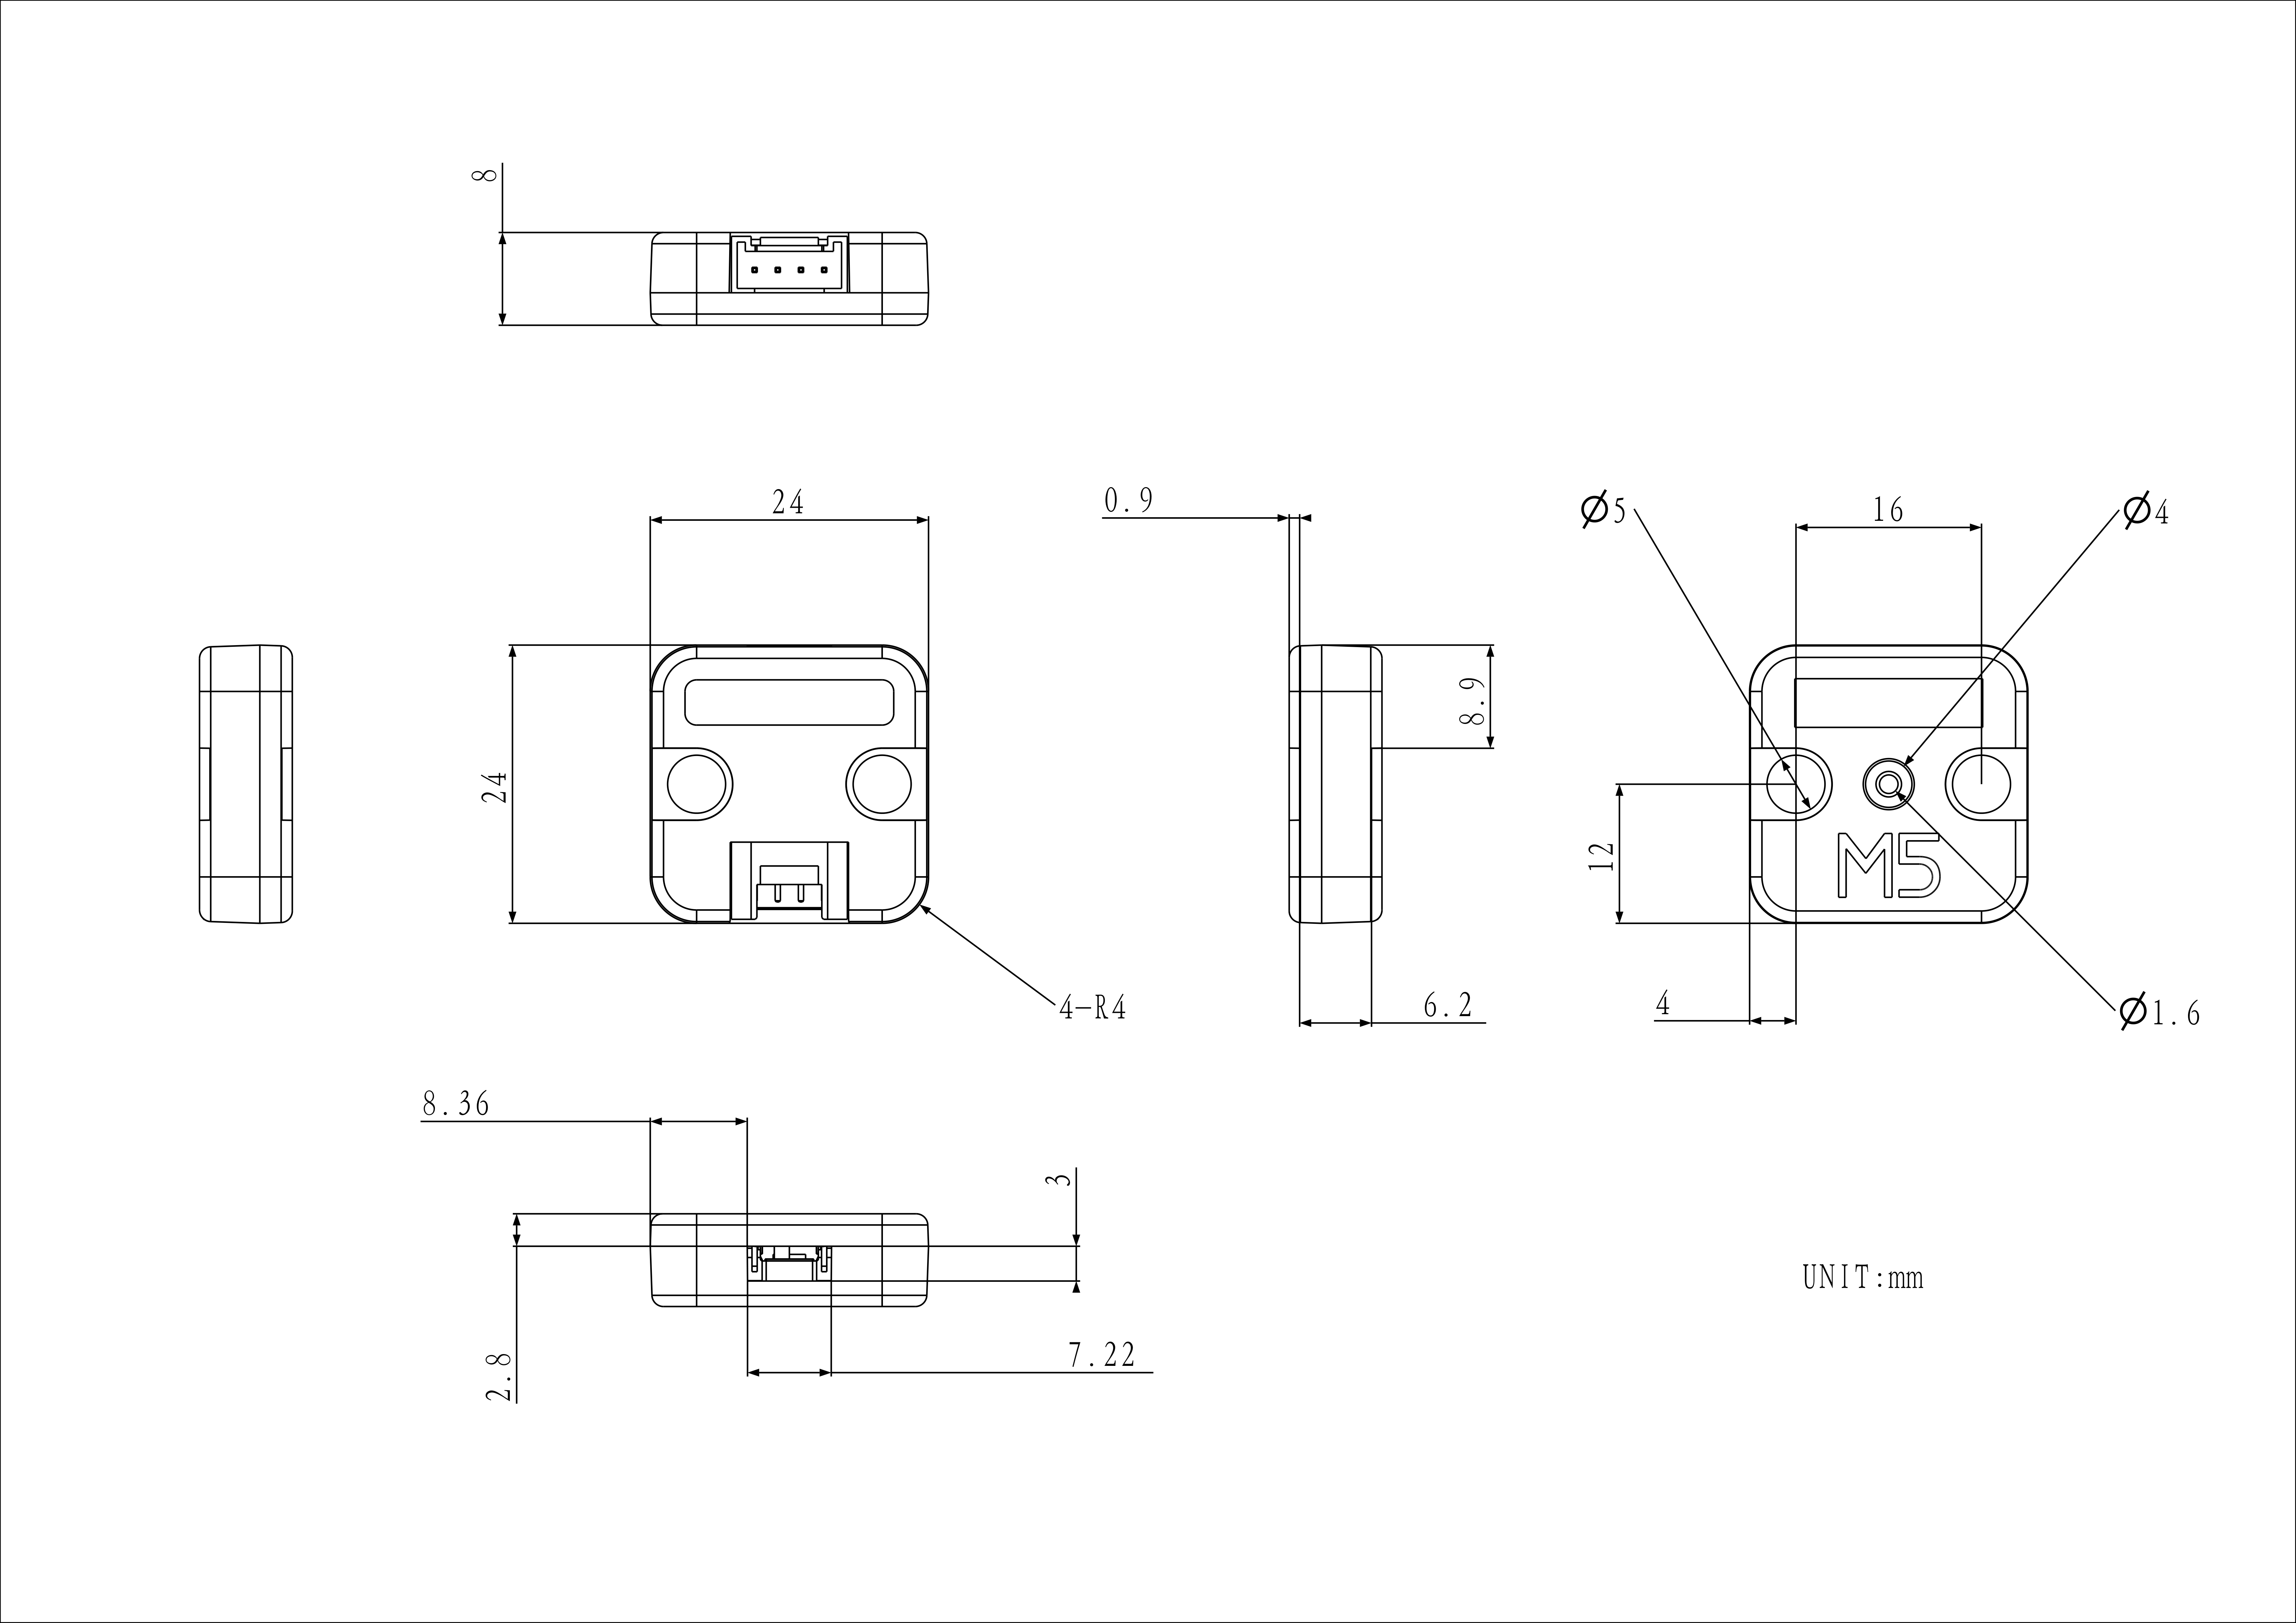
Structure
Softwares
Arduino
UiFlow2
Video
Product Comparison
| Product Comparison | Unit DoF6 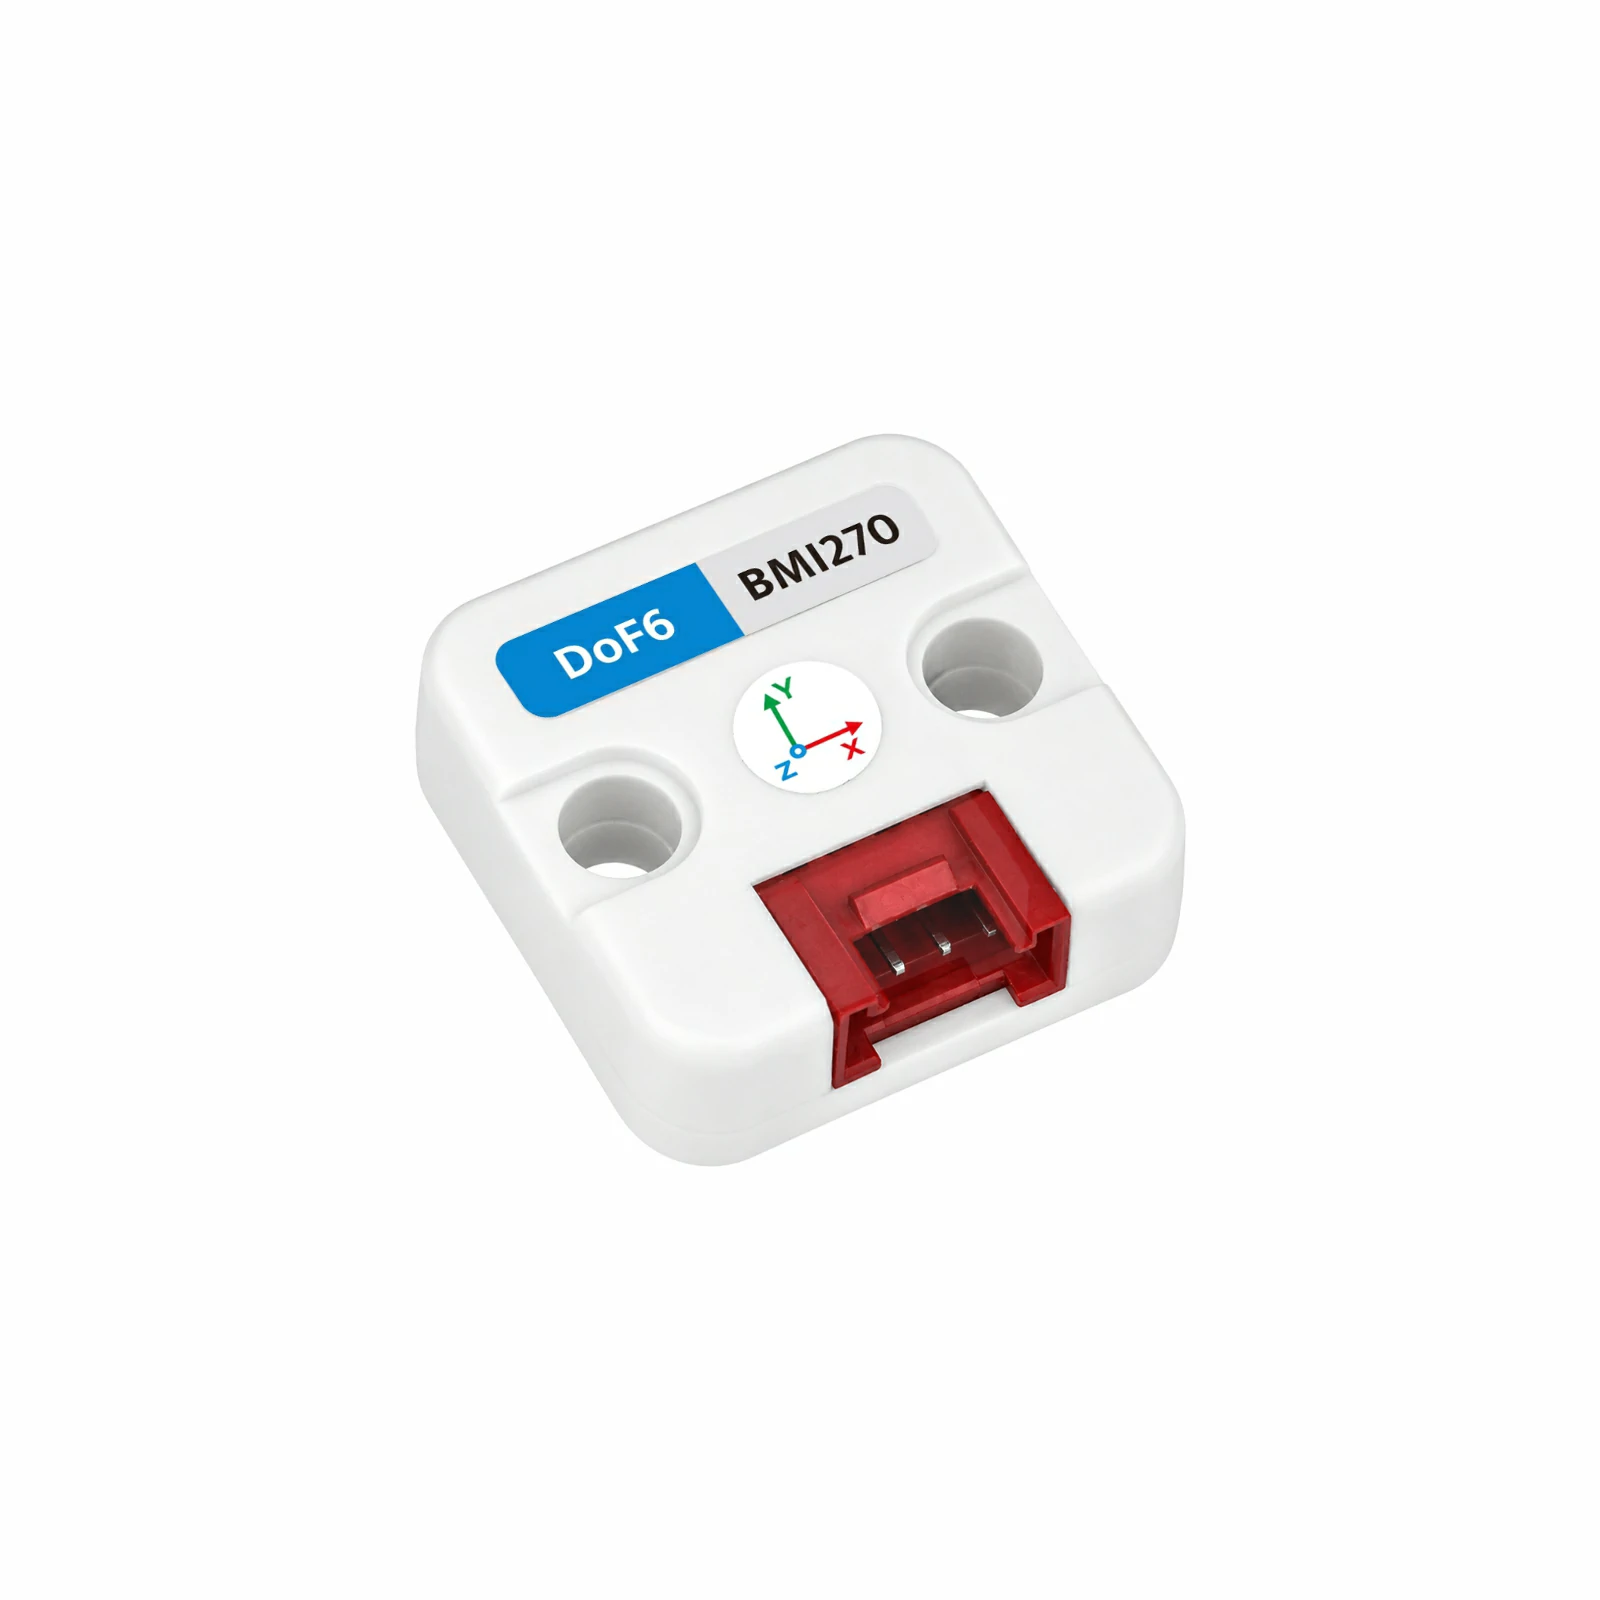 | Unit DoF9 | Unit DoF10 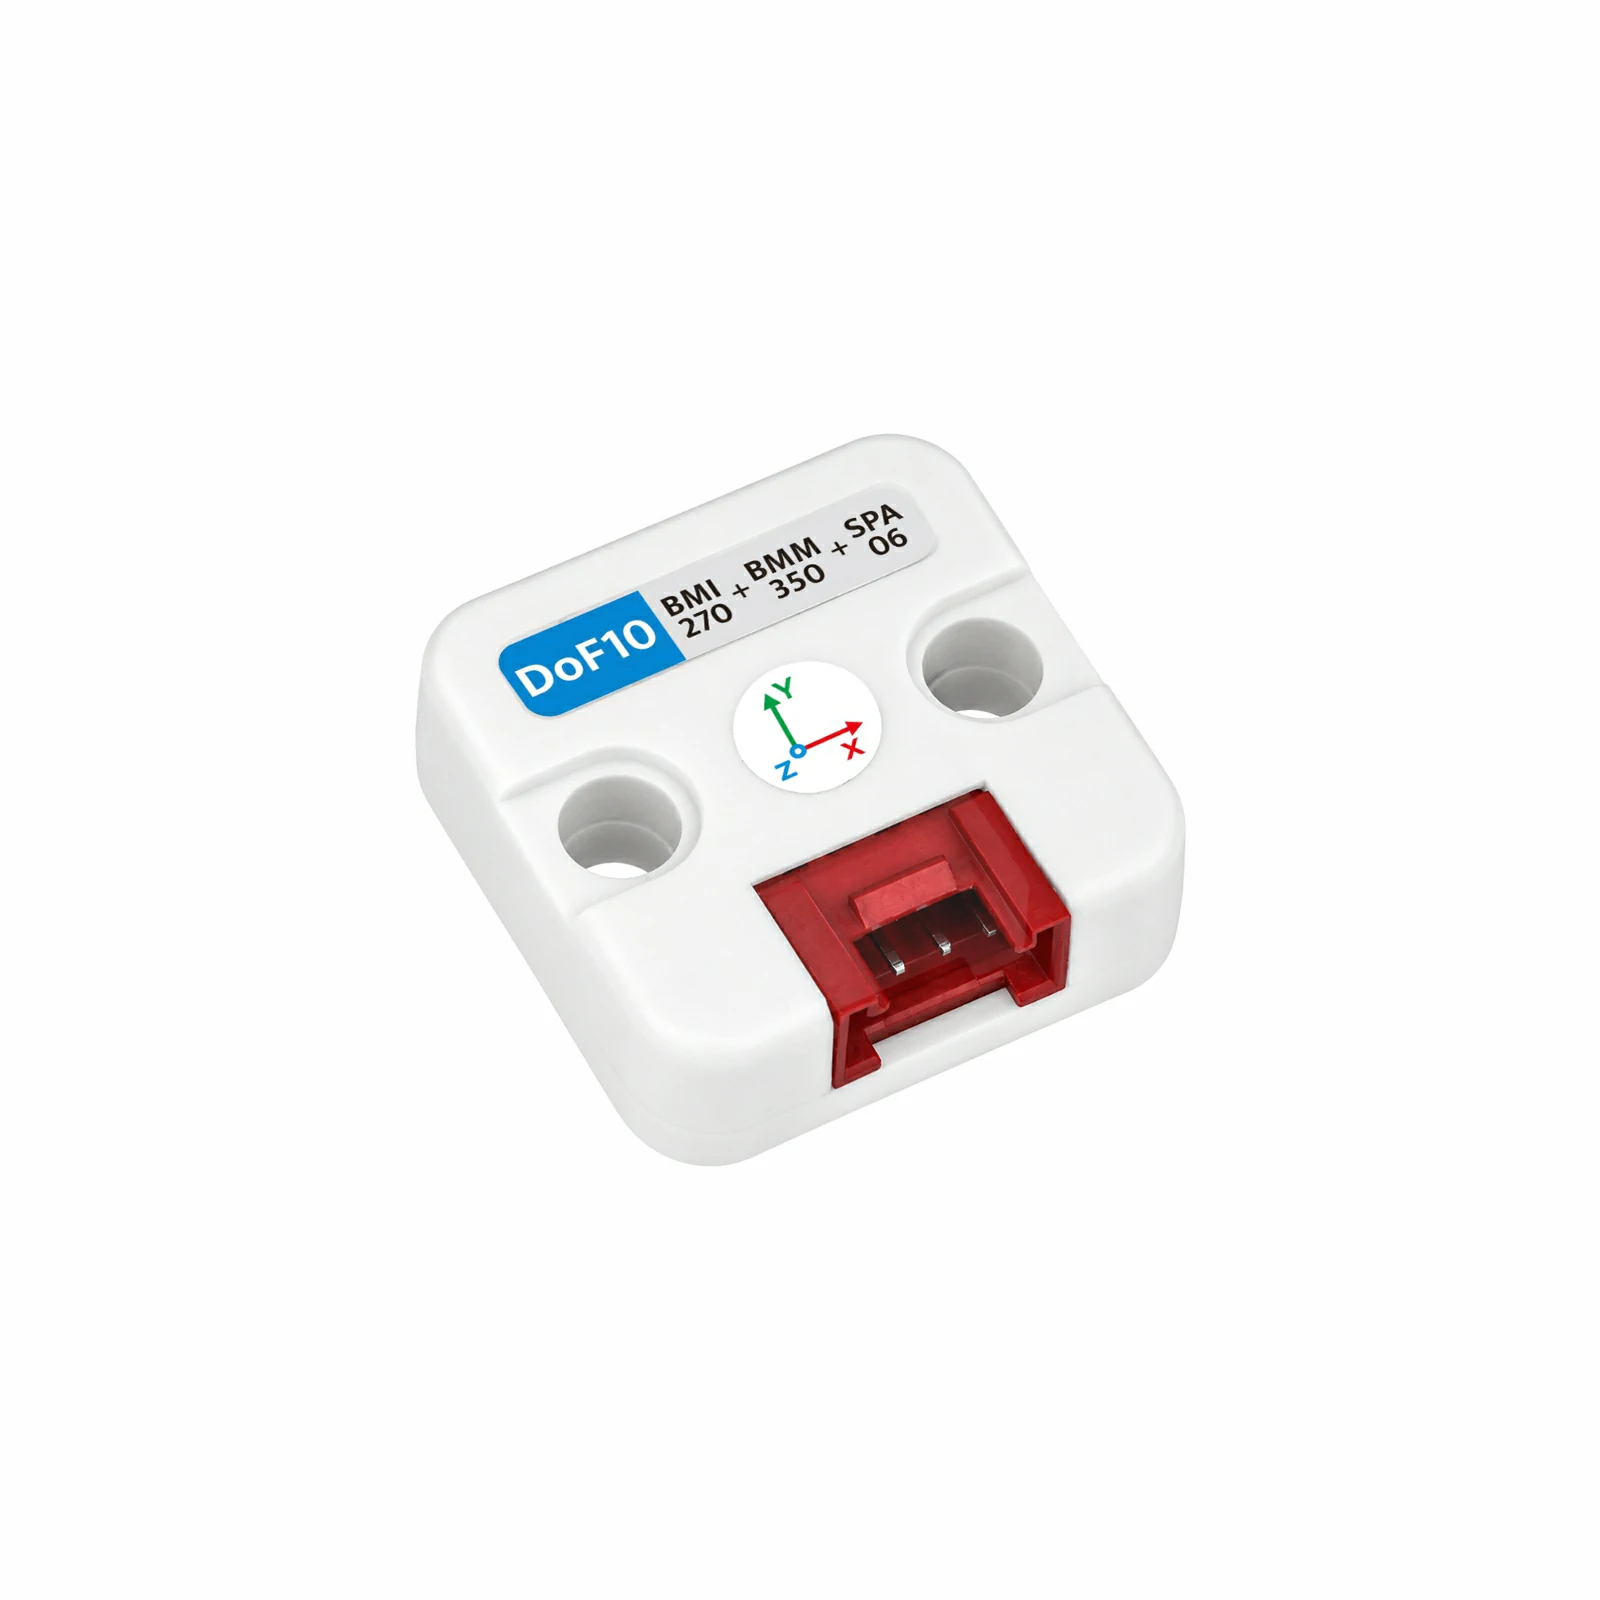 | Unit BMM350 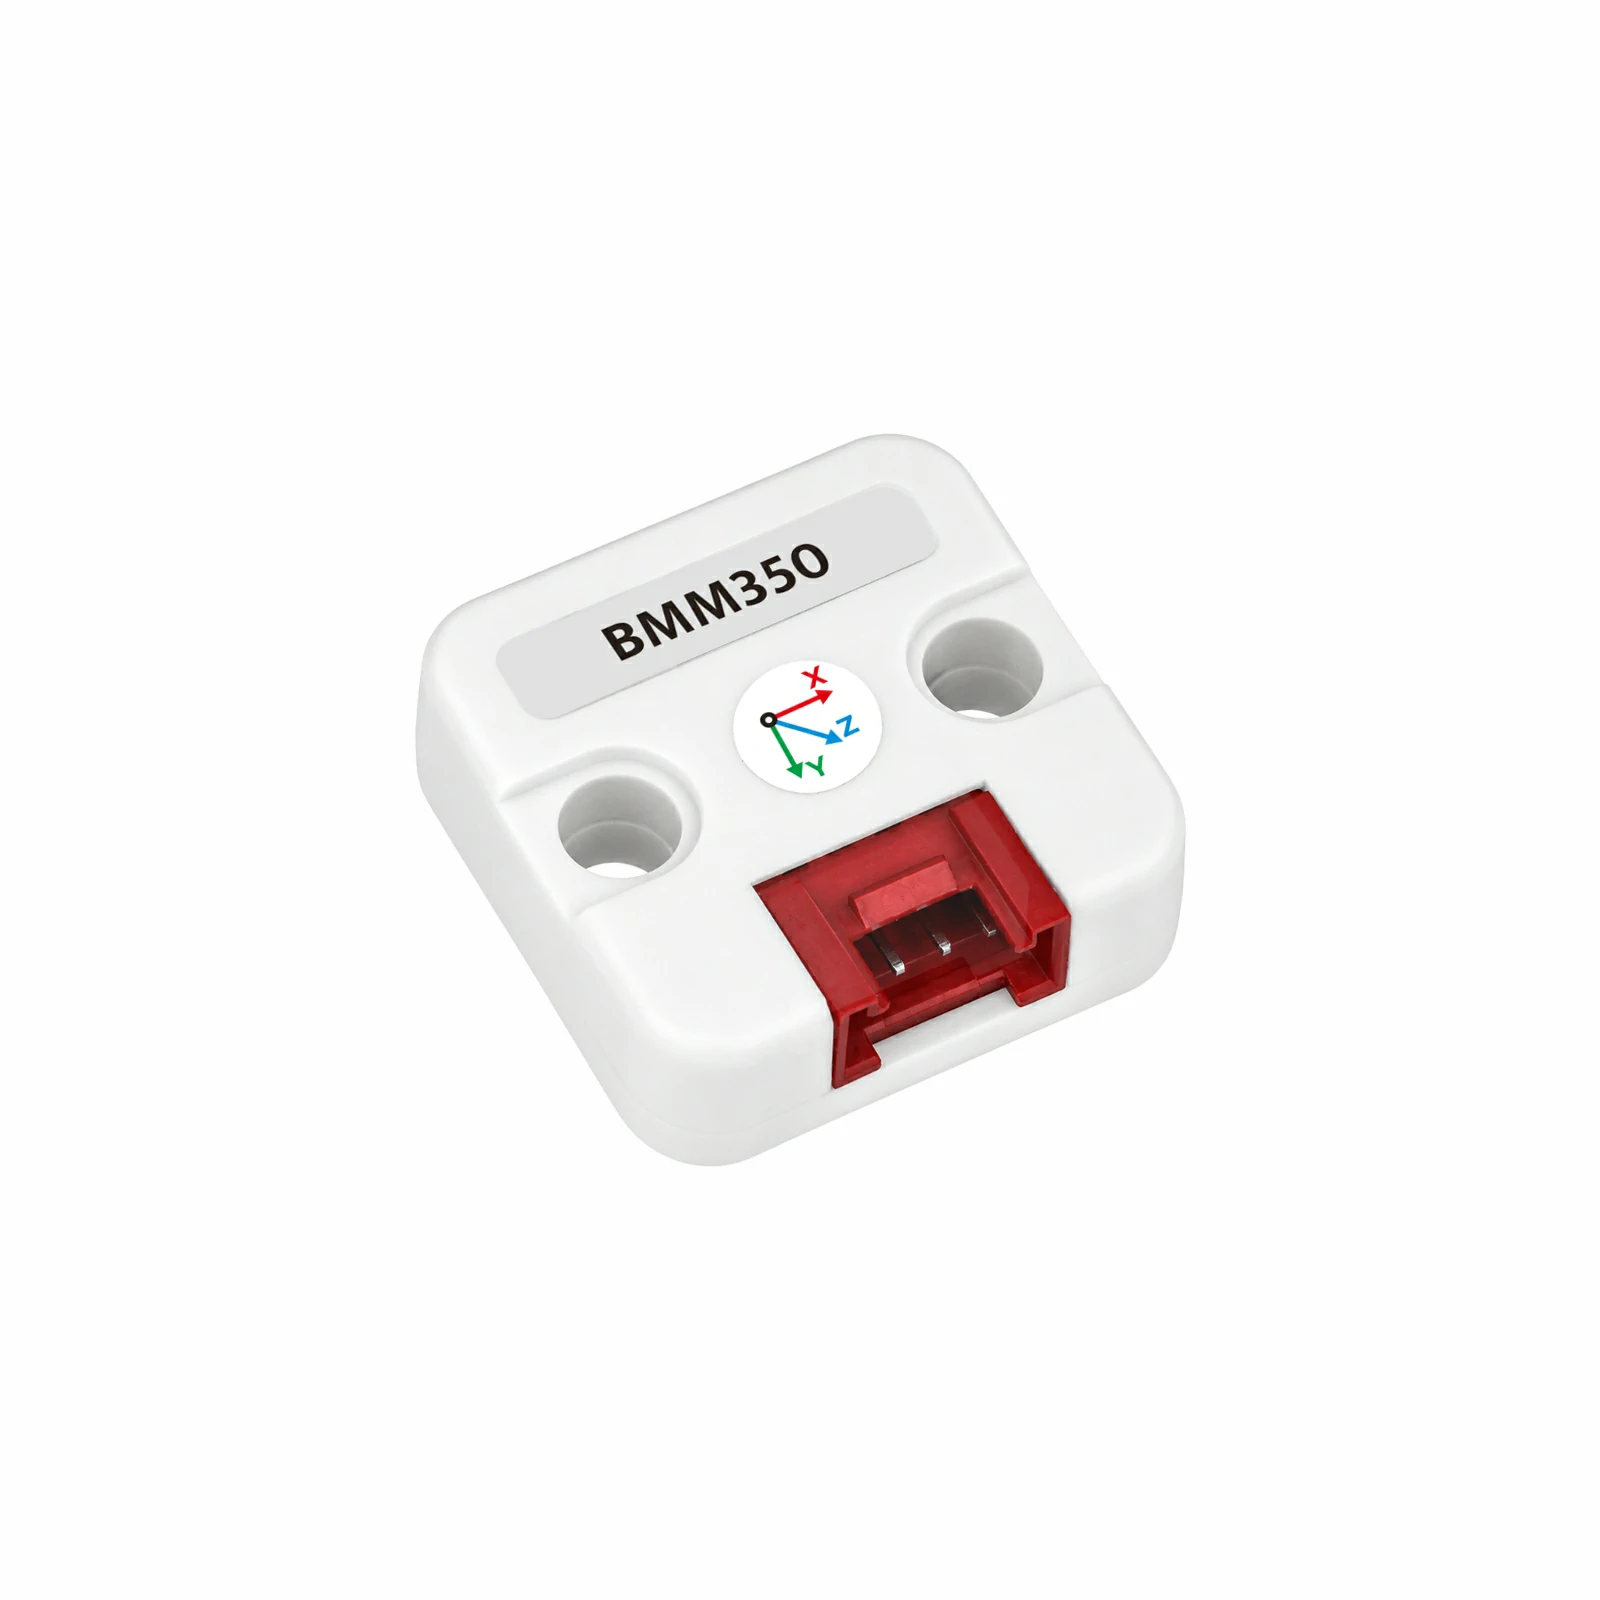 |
|---|---|---|---|---|
| Sensor Combination | BMI270 | BMI270 + BMM350 | BMI270 + BMM350 + SPA06-003 | BMM350 |
| Sensor Type | Six-axis inertial sensor | Six-axis inertial + three-axis geomagnetic sensor | Six-axis inertial + three-axis geomagnetic + barometric pressure sensor | Three-axis geomagnetic sensor |
| Accelerometer | 16-bit 3-axis | 16-bit 3-axis | 16-bit 3-axis | ❌ |
| Gyroscope | 16-bit 3-axis | 16-bit 3-axis | 16-bit 3-axis | ❌ |
| Magnetometer | ❌ | BMM350 (TMR, approx. 0.1 μT) | BMM350 (TMR, approx. 0.1 μT) | BMM350 (TMR, approx. 0.1 μT) |
| Barometric Pressure Sensor | ❌ | ❌ | SPA06-003 | ❌ |
| I2C Address | 0x68 / 0x69 (onboard switch) | BMI270: 0x68 / 0x69 (onboard switch) BMM350: 0x14 | BMI270: 0x68 / 0x69 (onboard switch) BMM350: 0x14 SPA06-003: 0x76 | 0x14 |
| Main Functions | Acceleration, angular velocity, and temperature acquisition; on-chip motion detection | Acceleration, angular velocity, temperature, and three-axis magnetic field acquisition; on-chip motion detection | Acceleration, angular velocity, temperature, three-axis magnetic field, and pressure acquisition; on-chip motion detection | Three-axis magnetic field acquisition; heading output after calibration |