

Arduino Quick Start
2. Devices & Examples
Demo Board-SHT30
3. M5Unified
4. M5GFX
5. Extensions
Unit
Module
Atomic
Tab5
IoT
Accessories
Chain ENV Tutorial
1. Preparation
Environment Setup: Refer to the Arduino IDE Getting Started Guide to complete the IDE installation, then install the corresponding board package and required driver libraries for the development board you are using.
Required Driver Library:
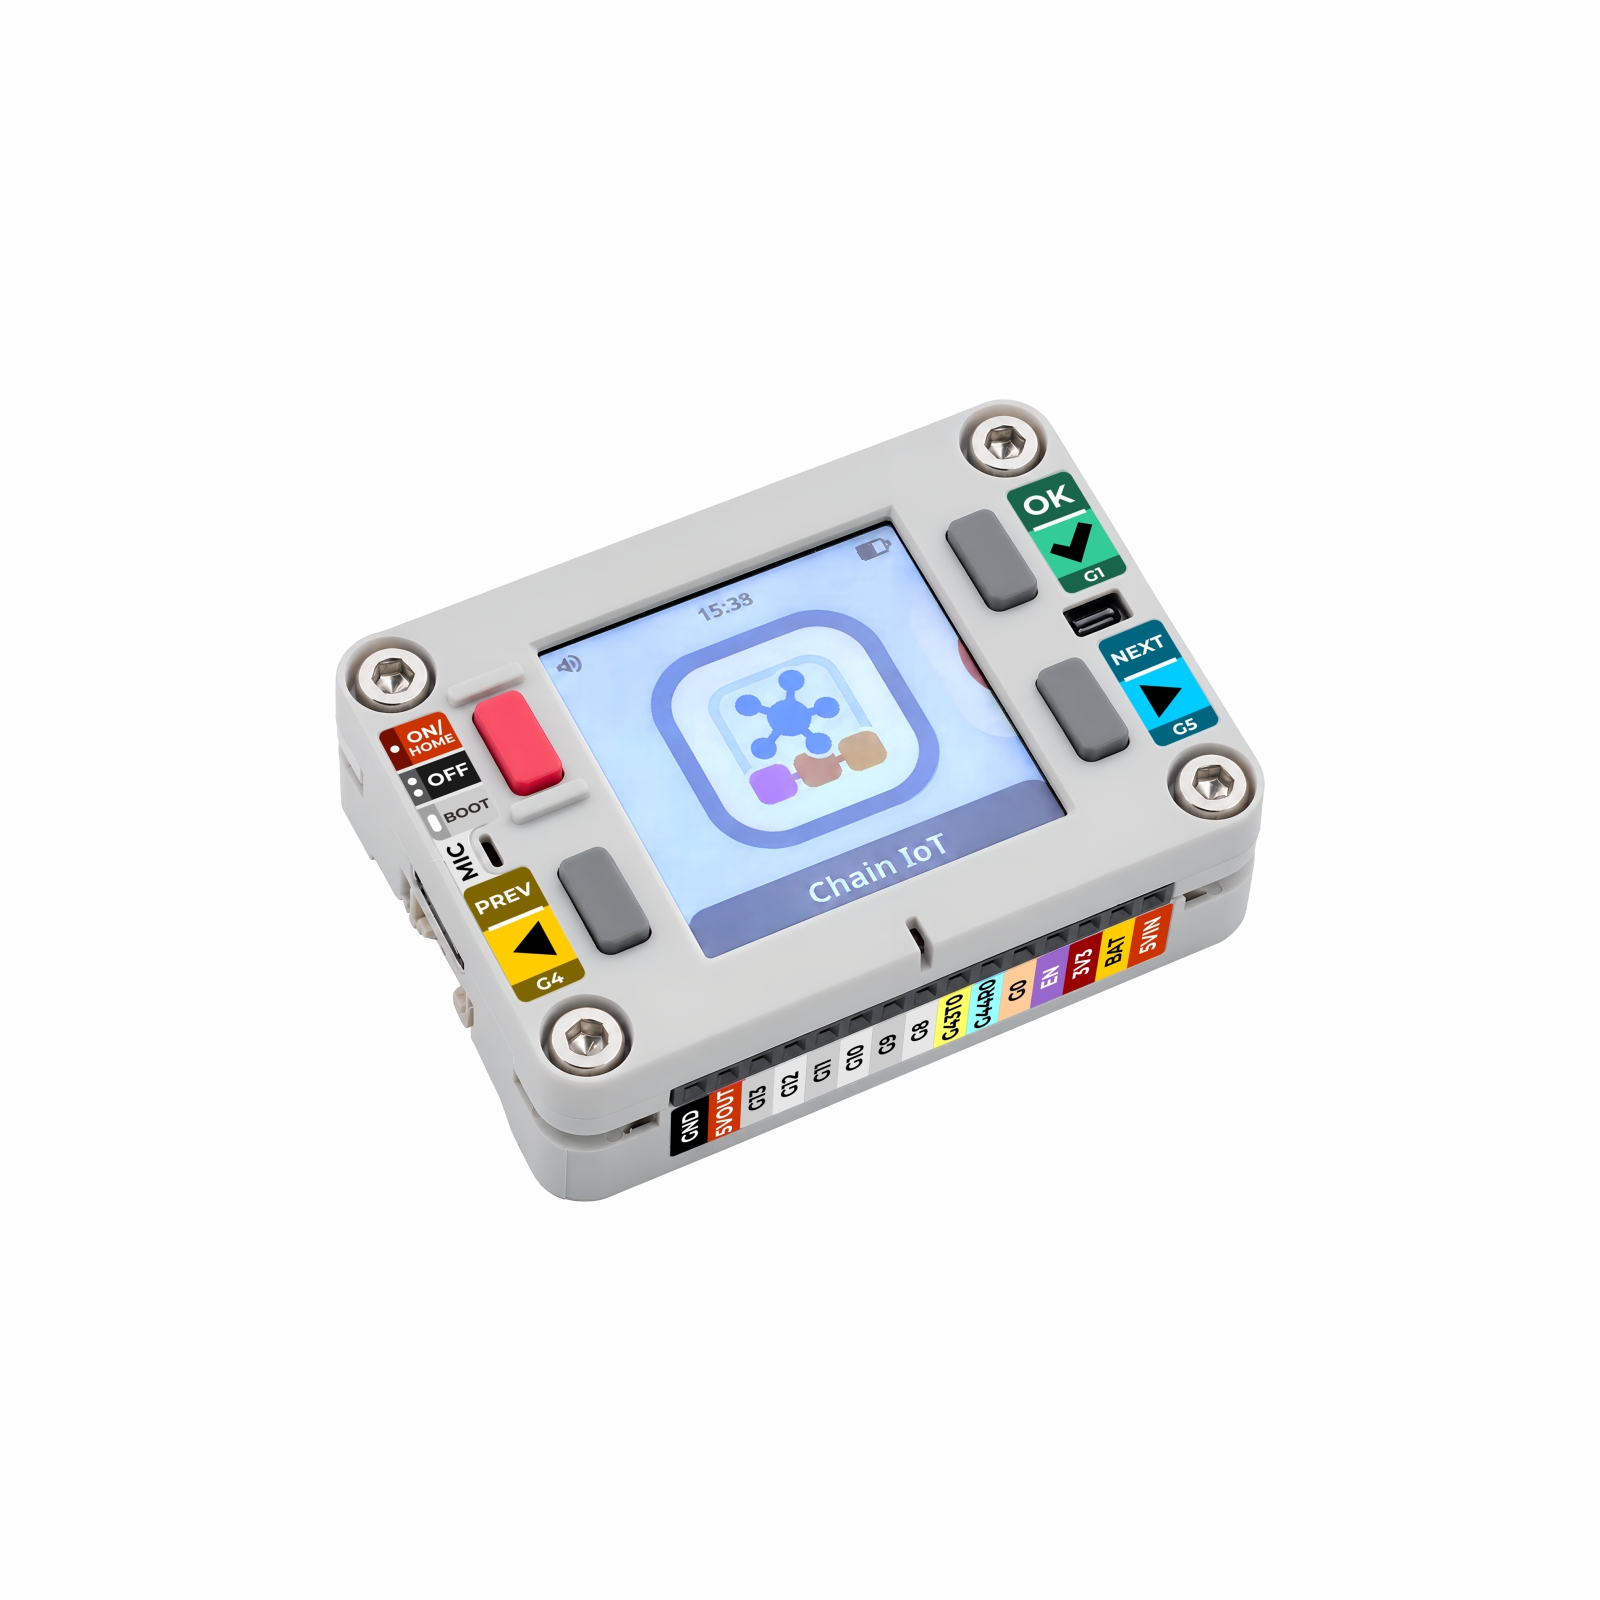
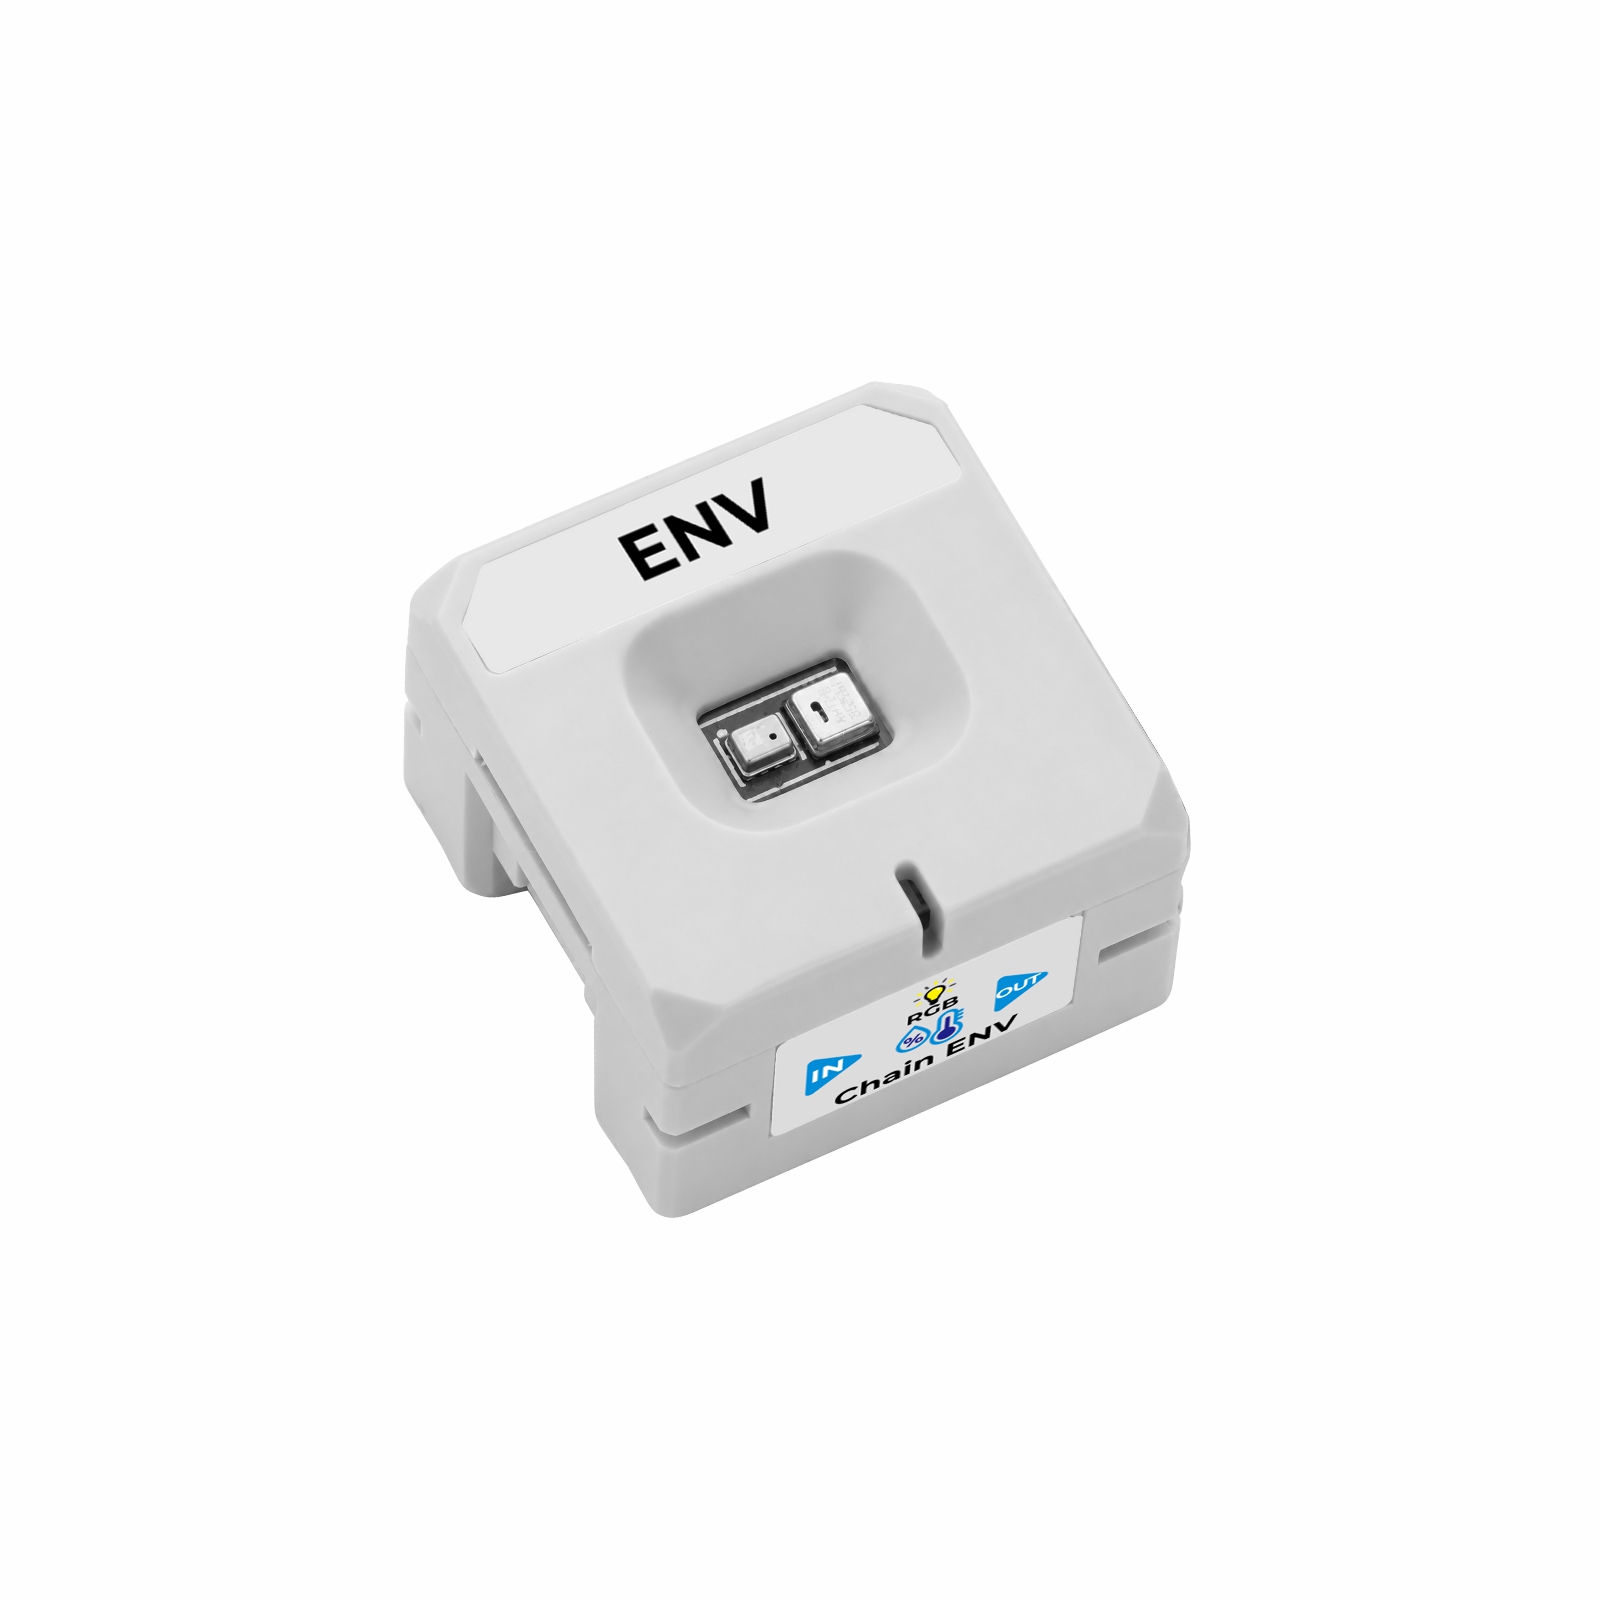
Required Hardware Products:
2. Example Program
M5Chain Library Version >= 1.0.10
M5Unified Library Version >= 0.3.0
M5GFX Library Version >= 0.3.0
In Arduino IDE, select M5ChainCaptain from the Board menu and select the corresponding serial port.
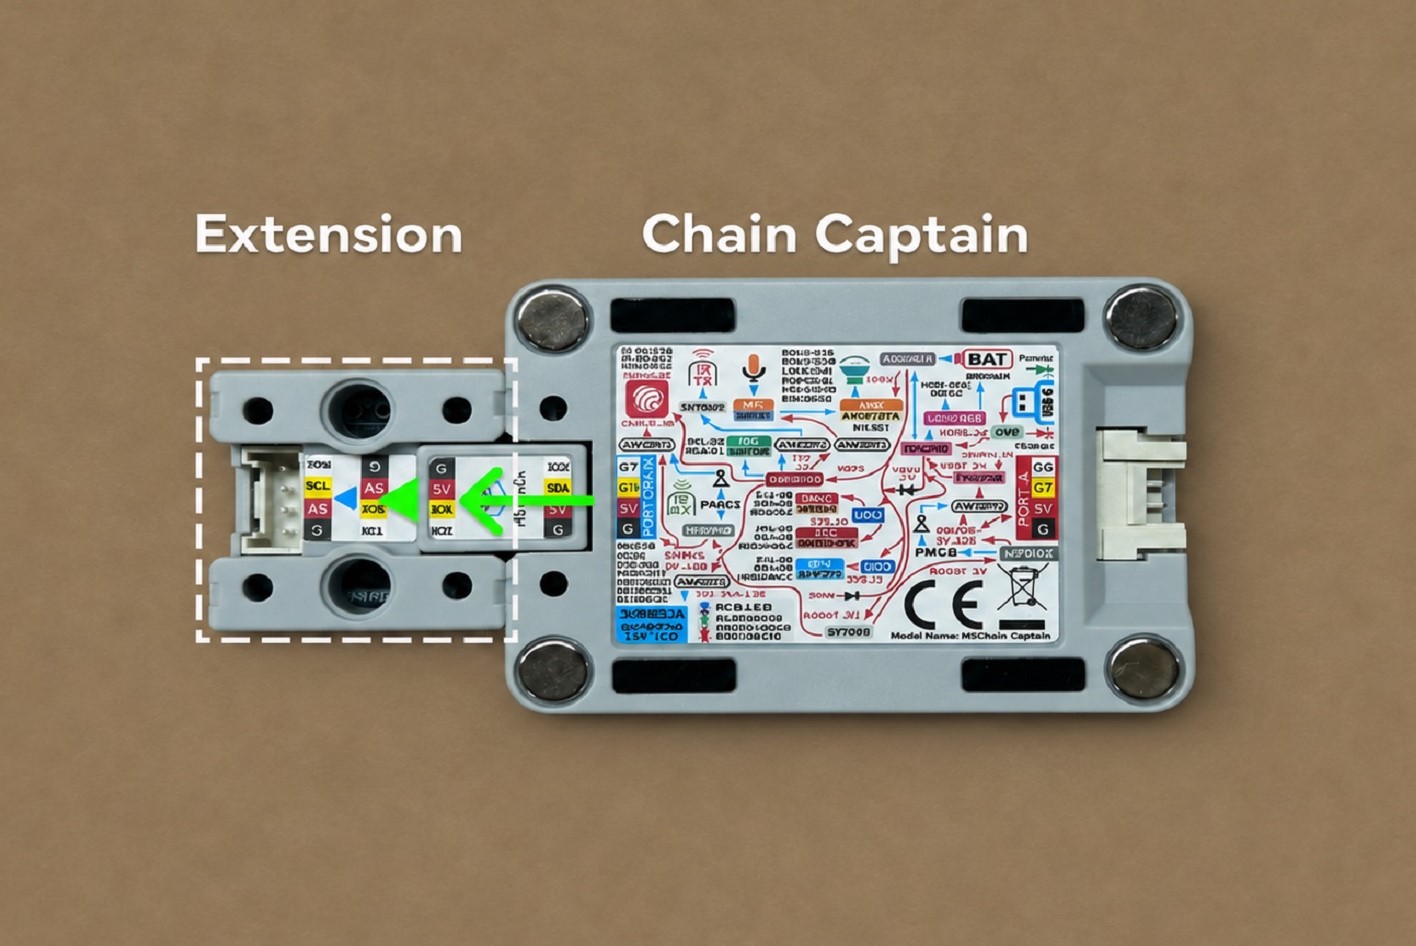
Use the Chain Bridge connector to link the main controller Chain Captain with Chain ENV. Pay attention to the orientation: the triangular arrow points outward from the main controller Chain Captain, as shown below:
TXD_PIN = GPIO_NUM_18 (GPIO18)
This example uses the Chain port on Chain Captain, with GPIO17 as RX and GPIO18 as TX, which corresponds to UART1. If you use a different host device, modify RXD_PIN and TXD_PIN in the program according to the actual wiring.
2.1 Read Environment Data
Chain ENV integrates an AHT20 temperature and humidity sensor and an SPA06 barometric pressure sensor. This example reads temperature and humidity through getAHT20Data(), and temperature, pressure and altitude through getSPA06Data(), then displays them on the Chain Captain screen in real time. The program automatically waits for Chain ENV to power up and retries for up to about 5 seconds; if the device is still not detected, the screen shows ENV ERROR.
#include <M5Chain.h>
#include <M5Unified.h>

#define RXD_PIN GPIO_NUM_17  // Chain Captain Chain RX
#define TXD_PIN GPIO_NUM_18  // Chain Captain Chain TX

// Maximum number of devices handled by this demo.
constexpr uint8_t MAX_DEVICES = 16;

Chain M5Chain;
uint8_t env_id = 0;

void applyTitleFont()
{
    // FreeSans is rounder and softer than the default bitmap font.
    M5.Display.setFont(&fonts::FreeSans18pt7b);
    M5.Display.setTextSize(1);
}

void applyBodyFont()
{
    M5.Display.setFont(&fonts::FreeSans12pt7b);
    M5.Display.setTextSize(1);
}

void showStatus(const char *text, uint16_t color)
{
    // Show one centered status message on the Chain Captain display.
    M5.Display.fillScreen(TFT_BLACK);
    M5.Display.setTextDatum(middle_center);
    M5.Display.setTextColor(color, TFT_BLACK);
    applyBodyFont();
    M5.Display.drawString(text, M5.Display.width() / 2, M5.Display.height() / 2);
}

bool findENV()
{
    // The ENV node needs a short startup time after Chain 5V is enabled.
    // Retry for about 5 seconds before reporting an error.
    for (uint8_t attempt = 0; attempt < 10; ++attempt) {
        if (M5Chain.isDeviceConnected(3)) {
            uint16_t device_count = 0;
            if (M5Chain.getDeviceNum(&device_count) == CHAIN_OK &&
                device_count > 0 && device_count <= MAX_DEVICES) {
                device_info_t devices[MAX_DEVICES];
                device_list_t device_list{device_count, devices};
                if (M5Chain.getDeviceList(&device_list)) {
                    for (uint16_t i = 0; i < device_count; ++i) {
                        if (devices[i].device_type == CHAIN_ENV_TYPE_CODE) {
                            env_id = devices[i].id;
                            return true;
                        }
                    }
                }
            }
        }
        delay(500);
    }
    return false;
}

void showEnvironment(float aht_temp, uint8_t humidity,
                     float pressure, float altitude)
{
    char line[32];
    const int cx = M5.Display.width() / 2;

    M5.Display.fillScreen(TFT_BLACK);
    M5.Display.setTextDatum(middle_center);

    M5.Display.setTextColor(TFT_WHITE, TFT_BLACK);
    applyTitleFont();
    M5.Display.drawString("CHAIN ENV", cx, 24);

    M5.Display.setTextColor(TFT_GREEN, TFT_BLACK);
    applyBodyFont();
    snprintf(line, sizeof(line), "TEMP  %.2f C", aht_temp);
    M5.Display.drawString(line, cx, 72);

    snprintf(line, sizeof(line), "HUMI  %u %%RH", (unsigned)humidity);
    M5.Display.drawString(line, cx, 108);

    M5.Display.setTextColor(TFT_CYAN, TFT_BLACK);
    snprintf(line, sizeof(line), "PRESS %.1f hPa", pressure);
    M5.Display.drawString(line, cx, 152);

    snprintf(line, sizeof(line), "ALT   %.1f m", altitude);
    M5.Display.drawString(line, cx, 188);
}

void setup()
{
    // Chain Captain uses M5IOE1 for display and power control.
    // Wait for the expander to finish booting before M5.begin().
    delay(520);

    auto cfg = M5.config();
    cfg.serial_baudrate = 115200;
    M5.begin(cfg);
    Serial.begin(115200);

    M5Chain.begin(&Serial1, 115200, RXD_PIN, TXD_PIN);

    // Chain power-up resets the panel; run the same init as M5.begin().
    M5.Display.init();
    M5.Display.setBrightness(255);

    showStatus("STARTING", TFT_WHITE);

    if (!findENV()) {
        Serial.println("Chain ENV not found");
        showStatus("ENV ERROR", TFT_RED);
        return;
    }

    Serial.printf("Chain ENV found, id=%u\n", (unsigned)env_id);
}

void loop()
{
    if (env_id == 0) {
        delay(1000);
        return;
    }

    int16_t aht_temp = 0;
    uint8_t humidity = 0;
    int16_t spa_temp = 0;
    uint16_t pressure = 0;
    int32_t altitude = 0;

    chain_status_t aht_status = M5Chain.getAHT20Data(env_id, &aht_temp, &humidity);
    chain_status_t spa_status = M5Chain.getSPA06Data(env_id, &spa_temp, &pressure, &altitude);

    if (aht_status != CHAIN_OK || spa_status != CHAIN_OK) {
        Serial.printf("Read failed: AHT20=%d SPA06=%d\n", aht_status, spa_status);
        showStatus("READ ERROR", TFT_RED);
        delay(1000);
        return;
    }

    float temp_c = aht_temp / 100.0f;
    float pressure_hpa = pressure / 10.0f;
    float altitude_m = altitude / 100.0f;

    Serial.printf("AHT20: %.2f C, %u %%RH\n", temp_c, (unsigned)humidity);
    Serial.printf("SPA06: %.2f C, %.1f hPa, %.2f m\n",
                  spa_temp / 100.0f, pressure_hpa, altitude_m);

    showEnvironment(temp_c, humidity, pressure_hpa, altitude_m);
    delay(1000);
}
After uploading the program, the screen displays the AHT20 temperature and humidity along with the SPA06 pressure and altitude. The serial output is as follows:
Chain ENV found, id=1
AHT20: 26.32 C, 66 %RH
SPA06: 27.76 C, 1009.5 hPa, 32.10 mThe temperature returned by getAHT20Data() is in units of 0.01°C and the humidity is in %RH; the temperature returned by getSPA06Data() is in units of 0.01°C, the pressure in 0.1hPa and the altitude in cm. The program converts these raw values accordingly.
2.2 Altitude Meter and Calibration
The SPA06 altitude reading is derived from the measured pressure:
Altitude_m = 44330 * [1 - (P / P0)^0.1903]
where P is the pressure measured by SPA06 and P0 is the local sea-level pressure. The device defaults to P0 = 1013.3 hPa; if this value differs from the actual local sea-level pressure, the altitude reading will be offset.
The following example is a complete altitude meter: after power-on it displays temperature, humidity, pressure, altitude and the current P0 in real time, and supports calibration with the buttons.
- Short press
OK: record the current altitude as 0 m and enter relative altitude mode; short pressPREVagain to return to absolute altitude mode. - Long press
OKfor 1 second: calibrate againstREFERENCE_ALTITUDE_CMand saveP0to the NVS of Chain Captain. - Short press
NEXT: writeSEA_LEVEL_PRESSURE_HPA_X10to ENV and save it to the NVS of Chain Captain.
Before use, change the two values at the top of the code according to your actual location:
SEA_LEVEL_PRESSURE_HPA_X10: the current local sea-level pressure in units of 0.1 hPa; for example, 1014.4 hPa is written as10144.REFERENCE_ALTITUDE_CM: the actual altitude of the Chain ENV location in cm; for example, 50.00 m is written as5000.
Choose either of the two absolute calibration methods. The result is stored in the NVS of Chain Captain and survives power loss; on every power-on the program automatically writes the saved P0 back to Chain ENV. The zeroing performed by a short press of OK only affects the display and is not written to NVS, so the device returns to absolute altitude mode after a restart.
#include <M5Chain.h>
#include <M5Unified.h>
#include <Preferences.h>
#include <math.h>
#include <type_traits>

#define RXD_PIN GPIO_NUM_17  // Chain Captain Chain RX
#define TXD_PIN GPIO_NUM_18  // Chain Captain Chain TX

// Local sea-level pressure in hPa x10. 1013.3 hPa -> 10133.
constexpr uint16_t SEA_LEVEL_PRESSURE_HPA_X10 = 10133;

// Known altitude of the sensor in cm, used by the long-press calibration.
constexpr int32_t REFERENCE_ALTITUDE_CM = 3210;

static_assert(SEA_LEVEL_PRESSURE_HPA_X10 >= 3000 &&
                  SEA_LEVEL_PRESSURE_HPA_X10 <= 11000,
              "Sea-level pressure must be 300.0 ~ 1100.0 hPa");


constexpr uint8_t MAX_DEVICES = 16;
constexpr uint32_t READ_INTERVAL_MS = 1000;
constexpr uint32_t HOLD_MS = 1000;

template <typename T>
struct FourthArg;

template <typename R, typename C, typename A1, typename A2, typename A3,
          typename A4, typename... Rest>
struct FourthArg<R (C::*)(A1, A2, A3, A4, Rest...)> {
    using type = A4;
};

using SetP0Arg = typename FourthArg<decltype(&Chain::setSPA06SeaLevelPressure)>::type;

Chain M5Chain;
Preferences prefs;
uint8_t env_id = 0;

int16_t aht_temp = 0;
uint8_t humidity = 0;
int16_t spa_temp = 0;
uint16_t pressure = 0;
int32_t altitude_cm = 0;

bool relative_mode = false;
int32_t zero_offset_cm = 0;
uint16_t sea_level_pressure = 0;

char status_text[24] = "ABS MODE";
uint32_t status_until = 0;
bool hold_done = false;

void setStatus(const char *text, uint32_t duration = 3000)
{
    strncpy(status_text, text, sizeof(status_text) - 1);
    status_text[sizeof(status_text) - 1] = '\0';
    status_until = millis() + duration;
}

const char *currentStatus()
{
    if (millis() < status_until) {
        return status_text;
    }
    return relative_mode ? "REL MODE" : "ABS MODE";
}

bool findENV()
{
    // The ENV node needs a short startup time after Chain 5V is enabled.
    for (uint8_t attempt = 0; attempt < 10; ++attempt) {
        if (M5Chain.isDeviceConnected(3)) {
            uint16_t device_count = 0;
            if (M5Chain.getDeviceNum(&device_count) == CHAIN_OK &&
                device_count > 0 && device_count <= MAX_DEVICES) {
                device_info_t devices[MAX_DEVICES];
                device_list_t device_list{device_count, devices};
                if (M5Chain.getDeviceList(&device_list)) {
                    for (uint16_t i = 0; i < device_count; ++i) {
                        if (devices[i].device_type == CHAIN_ENV_TYPE_CODE) {
                            env_id = devices[i].id;
                            return true;
                        }
                    }
                }
            }
        }
        delay(500);
    }
    return false;
}

bool readP0()
{
    uint16_t p0 = 0;
    if (M5Chain.getSPA06SeaLevelPressure(env_id, &p0) != CHAIN_OK) {
        return false;
    }
    sea_level_pressure = p0;
    return true;
}

bool readSensors()
{
    bool ok = true;
    if (M5Chain.getAHT20Data(env_id, &aht_temp, &humidity) != CHAIN_OK) {
        ok = false;
    }
    if (M5Chain.getSPA06Data(env_id, &spa_temp, &pressure, &altitude_cm) != CHAIN_OK) {
        ok = false;
    }
    return ok;
}

uint16_t loadP0()
{
    if (!prefs.begin("chain_env", true)) {
        return SEA_LEVEL_PRESSURE_HPA_X10;
    }
    uint16_t p0 = prefs.getUShort("p0", SEA_LEVEL_PRESSURE_HPA_X10);
    prefs.end();
    return p0;
}

void saveP0(uint16_t p0)
{
    if (!prefs.begin("chain_env", false)) {
        return;
    }
    prefs.putUShort("p0", p0);
    prefs.end();
}

bool setP0(uint16_t p0)
{
    uint8_t operation_status = 0;
    // 1.0.10 uses the fourth argument as timeout; 1.0.11 uses it as save flag.
    const SetP0Arg arg = std::is_same<SetP0Arg, unsigned long>::value
                             ? SetP0Arg(100)
                             : SetP0Arg(0);
    chain_status_t status = M5Chain.setSPA06SeaLevelPressure(
        env_id, p0, &operation_status, arg);
    return status == CHAIN_OK && operation_status == 1;
}

bool calibrateByReference()
{
    uint32_t pressure_sum = 0;
    uint8_t samples = 0;

    for (uint8_t i = 0; i < 16; ++i) {
        int16_t sample_temp = 0;
        uint16_t sample_pressure = 0;
        int32_t sample_altitude = 0;
        if (M5Chain.getSPA06Data(env_id, &sample_temp, &sample_pressure,
                                 &sample_altitude) == CHAIN_OK) {
            pressure_sum += sample_pressure;
            ++samples;
        }
        delay(250);
    }

    if (samples == 0) {
        return false;
    }

    const float average_hpa = pressure_sum / (10.0f * samples);
    const float reference_m = REFERENCE_ALTITUDE_CM / 100.0f;
    const float base = 1.0f - reference_m / 44330.0f;
    if (base <= 0.0f) {
        return false;
    }

    const float p0_hpa = average_hpa / powf(base, 1.0f / 0.1903f);
    const long p0_x10 = lroundf(p0_hpa * 10.0f);
    if (p0_x10 < 3000 || p0_x10 > 11000) {
        return false;
    }

    if (!setP0((uint16_t)p0_x10)) {
        return false;
    }
    saveP0((uint16_t)p0_x10);
    return true;
}

void drawScreen()
{
    char line[32];
    M5.Display.fillScreen(TFT_BLACK);

    M5.Display.setTextDatum(middle_center);
    M5.Display.setFont(&fonts::FreeSans12pt7b);
    M5.Display.setTextColor(TFT_WHITE, TFT_BLACK);
    M5.Display.drawString("CHAIN ENV", 120, 18);

    M5.Display.setTextDatum(middle_left);
    M5.Display.setFont(&fonts::FreeSans9pt7b);

    M5.Display.setTextColor(TFT_GREEN, TFT_BLACK);
    snprintf(line, sizeof(line), "TEMP  %.2f C", aht_temp / 100.0f);
    M5.Display.drawString(line, 16, 50);

    snprintf(line, sizeof(line), "HUMI  %u %%RH", (unsigned)humidity);
    M5.Display.drawString(line, 16, 80);

    M5.Display.setTextColor(TFT_CYAN, TFT_BLACK);
    snprintf(line, sizeof(line), "PRESS %.1f hPa", pressure / 10.0f);
    M5.Display.drawString(line, 16, 110);

    const int32_t shown_altitude = relative_mode ? (altitude_cm - zero_offset_cm) : altitude_cm;
    M5.Display.setTextDatum(middle_center);
    M5.Display.setFont(&fonts::FreeSans12pt7b);
    M5.Display.setTextColor(TFT_YELLOW, TFT_BLACK);
    snprintf(line, sizeof(line), "ALT %.2f m", shown_altitude / 100.0f);
    M5.Display.drawString(line, 120, 150);

    M5.Display.setFont(&fonts::FreeSans9pt7b);
    M5.Display.setTextColor(TFT_DARKGREY, TFT_BLACK);
    if (sea_level_pressure != 0) {
        snprintf(line, sizeof(line), "%s  P0 %.1f", relative_mode ? "REL" : "ABS",
                 sea_level_pressure / 10.0f);
    } else {
        snprintf(line, sizeof(line), "%s  P0 --", relative_mode ? "REL" : "ABS");
    }
    M5.Display.drawString(line, 120, 188);

    M5.Display.setTextColor(TFT_YELLOW, TFT_BLACK);
    M5.Display.drawString(currentStatus(), 120, 214);
}

void setup()
{
    // Chain Captain uses M5IOE1 for display and power control.
    // Wait for the expander to finish booting before M5.begin().
    delay(520);

    auto cfg = M5.config();
    cfg.serial_baudrate = 115200;
    M5.begin(cfg);
    Serial.begin(115200);

    M5Chain.begin(&Serial1, 115200, RXD_PIN, TXD_PIN);

    // Chain power-up resets the panel; run the same init as M5.begin().
    M5.Display.init();
    M5.Display.setBrightness(255);

    M5.Display.fillScreen(TFT_BLACK);
    M5.Display.setTextDatum(middle_center);
    M5.Display.setFont(&fonts::FreeSans12pt7b);
    M5.Display.setTextColor(TFT_WHITE, TFT_BLACK);
    M5.Display.drawString("STARTING", 120, 120);

    if (!findENV()) {
        Serial.println("Chain ENV not found");
        M5.Display.fillScreen(TFT_BLACK);
        M5.Display.setTextColor(TFT_RED, TFT_BLACK);
        M5.Display.drawString("ENV ERROR", 120, 120);
        return;
    }
    Serial.printf("Chain ENV found, id=%u\n", (unsigned)env_id);

    const uint16_t boot_p0 = loadP0();
    if (setP0(boot_p0)) {
        Serial.printf("P0 applied: %.1f hPa\n", boot_p0 / 10.0f);
    } else {
        Serial.println("P0 apply failed");
    }
    if (readP0()) {
        Serial.printf("P0: %.1f hPa\n", sea_level_pressure / 10.0f);
    } else {
        Serial.println("P0 read failed");
    }
    if (!readSensors()) {
        Serial.println("Sensor read failed");
    }
    drawScreen();

    M5.BtnA.setHoldThresh(HOLD_MS);
}

void loop()
{
    M5.update();

    static uint32_t last_read = 0;
    if (millis() - last_read >= READ_INTERVAL_MS) {
        last_read = millis();
        if (!readSensors()) {
            setStatus("READ ERR");
        }
        drawScreen();
    }

    if (M5.BtnA.isPressed()) {
        if (!hold_done && M5.BtnA.pressedFor(HOLD_MS)) {
            hold_done = true;
            setStatus("CALIBRATING", 8000);
            drawScreen();
            Serial.printf("Calibrating to %.2f m...\n", REFERENCE_ALTITUDE_CM / 100.0f);
            if (calibrateByReference()) {
                Serial.println("Calibration OK");
                relative_mode = false;
                readP0();
                readSensors();
                setStatus("CAL OK");
            } else {
                Serial.println("Calibration failed");
                setStatus("CAL ERR");
            }
            drawScreen();
        }
    } else {
        if (!hold_done && M5.BtnA.wasClicked()) {
            zero_offset_cm = altitude_cm;
            relative_mode = true;
            setStatus("REL ZERO");
            drawScreen();
        }
        hold_done = false;
    }

    if (M5.BtnB.wasClicked()) {
        relative_mode = false;
        setStatus("ABS MODE");
        drawScreen();
    }

    if (M5.BtnC.wasClicked()) {
        Serial.printf("Setting P0 to %.1f hPa...\n", SEA_LEVEL_PRESSURE_HPA_X10 / 10.0f);
        if (setP0(SEA_LEVEL_PRESSURE_HPA_X10)) {
            saveP0(SEA_LEVEL_PRESSURE_HPA_X10);
            Serial.println("P0 applied and stored");
            sea_level_pressure = SEA_LEVEL_PRESSURE_HPA_X10;
            relative_mode = false;
            readSensors();
            setStatus("P0 OK");
        } else {
            setStatus("P0 ERR");
        }
        drawScreen();
    }
}
P0 -- on the screen means the sea-level pressure read failed; CAL ERR means the long-press calibration failed. Long-press calibration with OK takes about 4 seconds, during which Chain ENV should be kept still. P0 can be set in the range of 300.0 ~ 1100.0 hPa; NEXT writes the value to NVS, so it does not need to be pressed on every power-on.
After successful calibration, the serial output is as follows:
Chain ENV found, id=1
P0 applied: 1013.3 hPa
P0: 1013.3 hPa
Calibrating to 32.10 m...
Calibration OK